mirror of
https://gitee.com/mirrors_PX4/PX4-Autopilot.git
synced 2026-11-04 18:11:35 +08:00

33 lines
1.7 KiB
Markdown
33 lines
1.7 KiB
Markdown
# PX4 Drag fusion parameter tuning algorithm
|
|
In PX4, drag fusion can be enabled in order to estimate the wind when flying a multirotor, assuming that the body vertical acceleration is produced by the rotors and that the lateral forces are produced by drag.
|
|
The model assumes a combination of:
|
|
1. momentum drag: created by the rotors changing the direction of the incoming air, linear to the relative airspeed. Parameter `EKF2_MCOEF`
|
|
2. bluff body drag: created by the wetted area of the aircraft, quadratic to the relative airspeed. Parameters `EKF2_BCOEF_X` and `EKF2_BCOEF_Y`
|
|
|
|
The python script was created to automate the tuning of the aforementioned parameters using flight test data.
|
|
|
|
## How to use this script
|
|
First, a flight log with enough information is required in order to accurately estimate the parameters.
|
|
The best way to do this is to fly the drone in altitude mode, accelerate to a moderate-high speed and let the drone slow-down by its own drag.
|
|
Repeat the same maneuver in all directions and several times to obtain a good dataset.
|
|
|
|
/!\ NOTE: the current state of this script assumes no wind. Some modifications are required to estimate both the wind and the parameters at the same time.
|
|
|
|
Then, install the required python packages:
|
|
```
|
|
pip install -r requirements.txt
|
|
```
|
|
and run the script and give it the log file as an argument:
|
|
```
|
|
python drag_replay.py <logfilename.ulg>
|
|
```
|
|
|
|
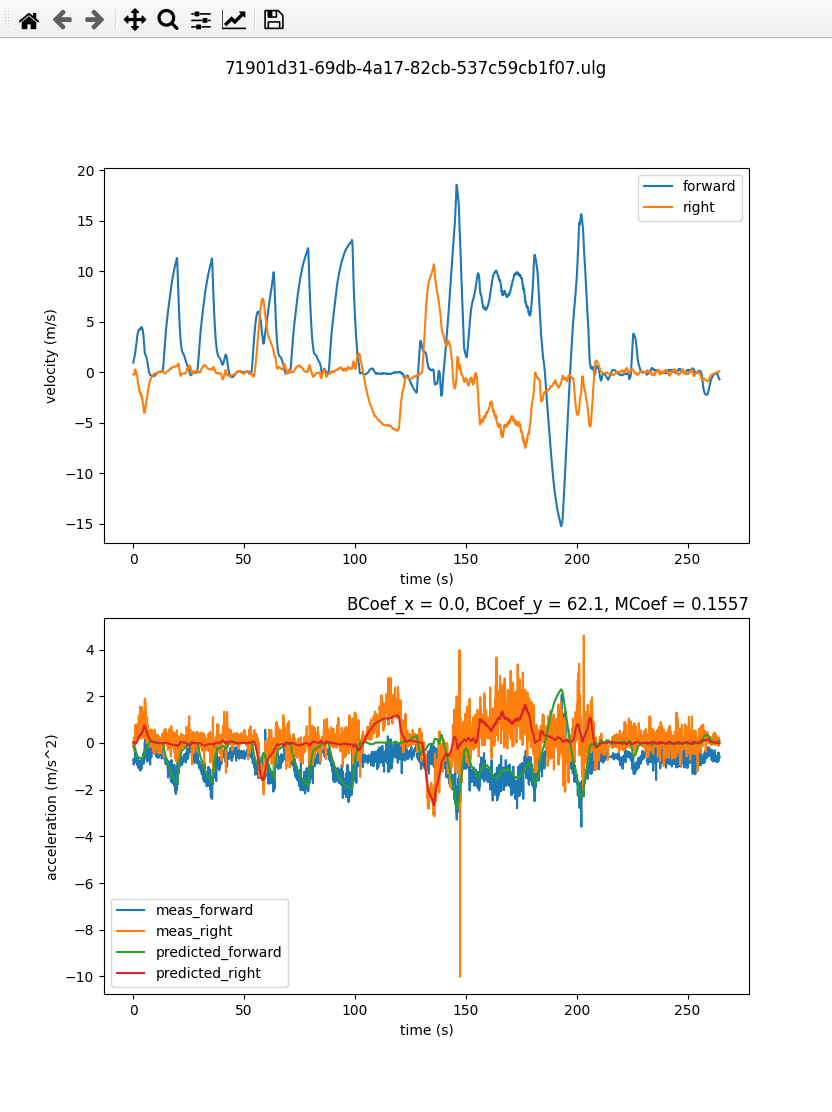
The estimated parameters are displayed in the console and the fit quality is shown in a plot:
|
|
```
|
|
param set EKF2_BCOEF_X 0.0
|
|
param set EKF2_BCOEF_Y 62.1
|
|
param set EKF2_MCOEF 0.16
|
|
/!\EXPERIMENTAL param set EKF2_DRAG_NOISE 0.31
|
|
```
|
|
|