# CUAV C-RTK
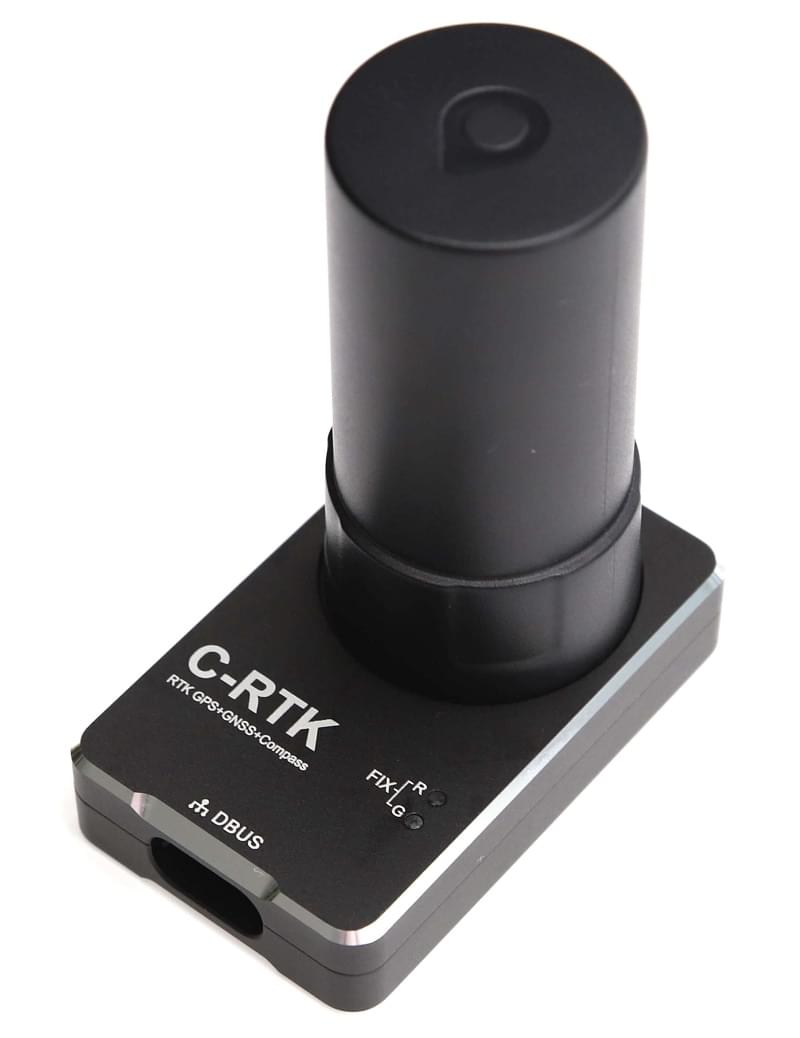
The [CUAV C-RTK GPS receiver](https://www.cuav.net/en/c-rtk-9ps-en/) is an [RTK GPS module](../gps_compass/rtk_gps.md) for the mass market.
A complete RTK system consists of at least two C-RTK modules \(one for the base station and the others for the aircraft\). Using RTK, PX4 can get its position with centimetre-level accuracy, which is much more accurate than can be provided by a normal GPS.
 ## Where to Buy
- [cuav taobao](https://item.taobao.com/item.htm?id=565380634341&spm=2014.21600712.0.0)
- [cuav aliexpress](https://www.aliexpress.com/item/32853894248.html?spm=2114.12010608.0.0.75592fadQKPPEn)
## Configuration
RTK setup and use on PX4 via _QGroundControl_ is largely plug and play \(see [RTK GPS](../gps_compass/rtk_gps.md) for more information\).
## Wiring and Connections
C-RTK GPS comes with a cable that terminates in a 6-pin connector and 4-pin connector that are compatible with [Pixhack v3](../flight_controller/pixhack_v3.md).
The 6-pin connector provides the interface for RTK GPS, and should be connected to the flight controller's GPS port.
The 4-pin connector is an m8n (standard) GPS interface that is intended for (optional) use as a second GPS.
:::tip
At time of writing PX4 does not yet fully support a second GPS. The 4-pin port need not be connected.
:::
 The cables/connectors may need to be modified in order to connect to other flight controller boards. The pin mappings for _Pixhawk 3 Pro_ and _Pixracer_ are shown below.
### Pinout
The C-RTK GPS pinout is provided below. This can be used to help modify the connector for other autopilot boards.
| pin | C-RTK GPS 6P | pin | Pixhawk 3 Pro GPS | C-RTK GPS 4P |
| --- | ------------ | --- | ----------------- | ------------ |
| 1 | SDA | 1 | VCC | |
| 2 | SCL | 2 | GPS_TX | |
| 3 | GPS_RX | 3 | GPS_RX | GPS_RX |
| 4 | GPS_TX | 4 | SCL | GPS_TX |
| 5 | VCC_5V | 5 | SDA | VCC_5v |
| 6 | GND | 6 | GND | GND |