mirror of
https://gitee.com/mirrors_PX4/PX4-Autopilot.git
synced 2026-10-29 16:33:33 +08:00
New Crowdin translations - ko (#26037)
Co-authored-by: Crowdin Bot <support+bot@crowdin.com>
This commit is contained in:
 PX4 Build Bot
co-authored by
Crowdin Bot
Crowdin Bot
parent
73e71feb47
commit
f90b1b375c
@@ -110,7 +110,7 @@ Follow _Source Installation_ instructions from [mavlink/mavros](https://github.c
|
||||
|
||||
- `PX4-Autopilot/src/modules/mavlink/mavlink/message_definitions/v1.0`
|
||||
- `workspace/src/mavlink/message_definitions/v1.0`
|
||||
are exactly the same.
|
||||
are exactly the same.
|
||||
|
||||
:::
|
||||
|
||||
|
||||
@@ -148,21 +148,21 @@ Now you are ready to do the build:
|
||||
2. 릴리스 또는 최신 버전을 사용하여 소스에서 MAVROS를 설치합니다.
|
||||
- 출시/안정
|
||||
|
||||
```sh
|
||||
rosinstall_generator --upstream mavros | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
```sh
|
||||
rosinstall_generator --upstream mavros | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
|
||||
- 최신 소스
|
||||
|
||||
```sh
|
||||
rosinstall_generator --upstream-development mavros | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
```sh
|
||||
rosinstall_generator --upstream-development mavros | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
|
||||
```sh
|
||||
# For fetching all the dependencies into your catkin_ws,
|
||||
# just add '--deps' to the above scripts, E.g.:
|
||||
# rosinstall_generator --upstream mavros --deps | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
```sh
|
||||
# For fetching all the dependencies into your catkin_ws,
|
||||
# just add '--deps' to the above scripts, E.g.:
|
||||
# rosinstall_generator --upstream mavros --deps | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
|
||||
3. Create workspace & deps
|
||||
|
||||
|
||||
@@ -38,9 +38,9 @@ Enable MAVLink on the serial port that you connect to the companion computer (se
|
||||
1. 하나는 자동조종장치의 UART 포트에 연결합니다.
|
||||
2. One connected to a ground station computer
|
||||
|
||||
Example radios include:
|
||||
Example radios include:
|
||||
|
||||
- [Digi International XBee Pro](https://www.digi.com/products/embedded-systems/digi-xbee/rf-modules/sub-1-ghz-rf-modules)
|
||||
- [Digi International XBee Pro](https://www.digi.com/products/embedded-systems/digi-xbee/rf-modules/sub-1-ghz-rf-modules)
|
||||
|
||||
[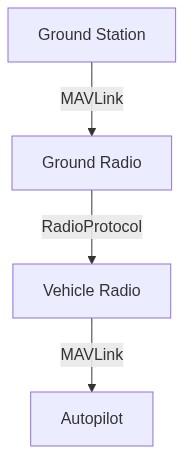](https://mermaid-js.github.io/mermaid-live-editor/#/edit/eyJjb2RlIjoiZ3JhcGggVEQ7XG4gIGduZFtHcm91bmQgU3RhdGlvbl0gLS1NQVZMaW5rLS0-IHJhZDFbR3JvdW5kIFJhZGlvXTtcbiAgcmFkMSAtLVJhZGlvUHJvdG9jb2wtLT4gcmFkMltWZWhpY2xlIFJhZGlvXTtcbiAgcmFkMiAtLU1BVkxpbmstLT4gYVtBdXRvcGlsb3RdOyIsIm1lcm1haWQiOnsidGhlbWUiOiJkZWZhdWx0In0sInVwZGF0ZUVkaXRvciI6ZmFsc2V9)
|
||||
|
||||
|
||||
Reference in New Issue
Block a user