mirror of
https://gitee.com/mirrors_PX4/PX4-Autopilot.git
synced 2026-10-03 14:48:54 +08:00
Move PX4 Guide source into /docs (#24490)
* Add vitepress tree

* Update existing workflows so they dont trigger on changes in the docs path

* Add nojekyll, package.json, LICENCE etc

* Add crowdin docs upload/download scripts

* Add docs flaw checker workflows

* Used docs prefix for docs workflows

* Crowdin obvious fixes

* ci: docs move to self hosted runner

runs on a beefy server for faster builds

Signed-off-by: Ramon Roche <mrpollo@gmail.com>

* ci: don't run build action for docs or ci changes

Signed-off-by: Ramon Roche <mrpollo@gmail.com>

* ci: update runners

Signed-off-by: Ramon Roche <mrpollo@gmail.com>

* Add docs/en

* Add docs assets and scripts

* Fix up editlinks to point to PX4 sources

* Download just the translations that are supported

* Add translation sources for zh, uk, ko

* Update latest tranlsation and uorb graphs

* update vitepress to latest

---------

Signed-off-by: Ramon Roche <mrpollo@gmail.com>
Co-authored-by: Ramon Roche <mrpollo@gmail.com>
This commit is contained in:
 Hamish Willee
co-authored by
Ramon Roche
Ramon Roche
parent
8e6d2ebe4a
commit
88d623bedb
@@ -0,0 +1,552 @@
|
||||
# Симуляція Gazebo Classic
|
||||
|
||||
:::warning
|
||||
_Gazebo Classic_ is supported with PX4 up to Ubuntu Linux 20.04.
|
||||
In Ubuntu 22.04 and later you must use [Gazebo](../sim_gazebo_gz/index.md) (which was [formerly known](https://www.openrobotics.org/blog/2022/4/6/a-new-era-for-gazebo) as "Gazebo Ignition").
|
||||
:::
|
||||
|
||||
Gazebo Classic - це потужне середовище 3D симуляції для автономних систем яке зокрема підходить для перевірки уникання об'єктів та комп'ютерного зору.
|
||||
Ця сторінка описує її використання з SITL та єдиним рухомим засобом.
|
||||
Gazebo Classic can also be used with [HITL](../simulation/hitl.md) and for [multi-vehicle simulation](../sim_gazebo_classic/multi_vehicle_simulation.md).
|
||||
|
||||
**Supported Vehicles:** Quad ([Iris](../airframes/airframe_reference.md#copter_quadrotor_x_generic_quadcopter), Hex (Typhoon H480), [Generic Standard VTOL (QuadPlane)](../airframes/airframe_reference.md#vtol_standard_vtol_generic_standard_vtol), Tailsitter, Plane, Rover, Submarine/UUV.
|
||||
|
||||
<lite-youtube videoid="qfFF9-0k4KA" title="PX4 Flight Stack ROS 3D Software in the Loop Simulation (SITL)"/>
|
||||
|
||||
[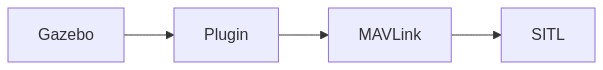](https://mermaid-js.github.io/mermaid-live-editor/#/edit/eyJjb2RlIjoiZ3JhcGggTFI7XG4gIEdhemViby0tPlBsdWdpbjtcbiAgUGx1Z2luLS0-TUFWTGluaztcbiAgTUFWTGluay0tPlNJVEw7IiwibWVybWFpZCI6eyJ0aGVtZSI6ImRlZmF1bHQifSwidXBkYXRlRWRpdG9yIjpmYWxzZX0)
|
||||
|
||||
<!-- original graph info
|
||||
graph LR;
|
||||
Gazebo-- >Plugin;
|
||||
Plugin-- >MAVLink;
|
||||
MAVLink-- >SITL;
|
||||
-->
|
||||
|
||||
:::info
|
||||
See [Simulation](../simulation/index.md) for general information about simulators, the simulation environment, and simulation configuration (e.g. supported vehicles).
|
||||
:::
|
||||
|
||||
## Встановлення
|
||||
|
||||
:::info
|
||||
If you plan to use PX4 with ROS you **should follow the** [ROS Instructions](../simulation/ros_interface.md) to install both ROS and Gazebo Classic (and thereby avoid installation conflicts).
|
||||
:::
|
||||
|
||||
Gazebo Classic setup is included in our [standard build instructions](../dev_setup/dev_env.md) for macOS, Ubuntu 18.04 and 20.04, and Windows on WSL2 for the same hosts.
|
||||
|
||||
For Ubuntu 22.04 LTS and later, the installation script ([/Tools/setup/ubuntu.sh](https://github.com/PX4/PX4-Autopilot/blob/main/Tools/setup/ubuntu.sh)) installs the [Gazebo](../sim_gazebo_gz/index.md) simulator instead.
|
||||
|
||||
If you want to use Gazebo Classic on Ubuntu 22.04 you can use the following commands to remove [Gazebo](../sim_gazebo_gz/index.md) (Harmonic) and then reinstall Gazebo-Classic 11:
|
||||
|
||||
```sh
|
||||
sudo apt remove gz-harmonic
|
||||
sudo apt install aptitude
|
||||
sudo aptitude install gazebo libgazebo11 libgazebo-dev
|
||||
```
|
||||
|
||||
Note that `aptitude` is needed because it can resolve dependency conflicts (by removing certain packages) that `apt` is unable to handle.
|
||||
|
||||
:::tip
|
||||
You could also modify the installation script to install Gazebo Classic on later versions before it is run for the first time.
|
||||
:::
|
||||
|
||||
Additional installation instructions can be found on gazebosim.org.
|
||||
|
||||
## Запуск симуляції
|
||||
|
||||
Виконайте симуляцію запустивши PX4 SITL та Gazebo Classic з налаштуванням планеру для завантаження (підтримуються мультикоптери, літаки, ВЗІП, оптичний потік так симуляції кількох засобів).
|
||||
|
||||
The easiest way to do this is to open a terminal in the root directory of the PX4 _PX4-Autopilot_ repository and call `make` for the desired target.
|
||||
Наприклад для запуску симуляції квадрокоптера (за замовчуванням):
|
||||
|
||||
```sh
|
||||
cd /path/to/PX4-Autopilot
|
||||
make px4_sitl gazebo-classic
|
||||
```
|
||||
|
||||
The supported vehicles and `make` commands are listed below (click links to see vehicle images).
|
||||
|
||||
:::info
|
||||
For the full list of build targets run `make px4_sitl list_vmd_make_targets` (and filter on those that start with `gazebo-classic_`).
|
||||
:::
|
||||
|
||||
| Транспортний засіб | Команда |
|
||||
| ------------------------------------------------------------------------------------------------------------------------------------------------------------------------ | --------------------------------------------------------- |
|
||||
| [Quadrotor](../sim_gazebo_classic/vehicles.md#quadrotor-default) | `make px4_sitl gazebo-classic` |
|
||||
| [Quadrotor with Optical Flow](../sim_gazebo_classic/vehicles.md#quadrotor-with-optical-flow) | `make px4_sitl gazebo-classic_iris_opt_flow` |
|
||||
| [Quadrotor with Depth Camera](../sim_gazebo_classic/vehicles.md#quadrotor-with-depth-camera) (forward-facing) | `make px4_sitl gazebo-classic_iris_depth_camera` |
|
||||
| [Quadrotor with Depth Camera](../sim_gazebo_classic/vehicles.md#quadrotor-with-depth-camera) (downward-facing) | `make px4_sitl gazebo-classic_iris_downward_depth_camera` |
|
||||
| [3DR Solo (Quadrotor)](../sim_gazebo_classic/vehicles.md#3dr-solo-quadrotor) | `make px4_sitl gazebo-classic_solo` |
|
||||
| <a id="typhoon_h480"></a>[Typhoon H480 (Hexrotor)](../sim_gazebo_classic/vehicles.md#typhoon-h480-hexrotor) (with video streaming) | `make px4_sitl gazebo-classic_typhoon_h480` |
|
||||
| [Standard Plane](../sim_gazebo_classic/vehicles.md#standard-plane) | `make px4_sitl gazebo-classic_plane` |
|
||||
| [Standard Plane (with catapult launch)](../sim_gazebo_classic/vehicles.md#standard-plane-with-catapult-launch) | `make px4_sitl gazebo-classic_plane_catapult` |
|
||||
| [Standard VTOL](../sim_gazebo_classic/vehicles.md#standard-vtol) | `make px4_sitl gazebo-classic_standard_vtol` |
|
||||
| [Tailsitter VTOL](../sim_gazebo_classic/vehicles.md#tailsitter-vtol) | `make px4_sitl gazebo-classic_tailsitter` |
|
||||
| [Ackerman UGV (Rover)](../sim_gazebo_classic/vehicles.md#ackermann-ugv) | `make px4_sitl gazebo-classic_rover` |
|
||||
| [Differential UGV (Rover)](../sim_gazebo_classic/vehicles.md#differential-ugv) | `make px4_sitl gazebo-classic_r1_rover` |
|
||||
| [HippoCampus TUHH (UUV: Unmanned Underwater Vehicle)](../sim_gazebo_classic/vehicles.md#unmanned-underwater-vehicle-uuv-submarine) | `make px4_sitl gazebo-classic_uuv_hippocampus` |
|
||||
| [Boat (USV: Unmanned Surface Vehicle)](../sim_gazebo_classic/vehicles.md#hippocampus-tuhh-uuv) | `make px4_sitl gazebo-classic_boat` |
|
||||
| [Cloudship (Airship)](../sim_gazebo_classic/vehicles.md#airship) | `make px4_sitl gazebo-classic_cloudship` |
|
||||
|
||||
:::info
|
||||
The [Installing Files and Code](../dev_setup/dev_env.md) guide is a useful reference if there are build errors.
|
||||
:::
|
||||
|
||||
Вищенаведені команди запускають єдиний засіб з повним користувацьким інтерфейсом.
|
||||
Інші варіанти включають:
|
||||
|
||||
- [Starting PX4 and Gazebo separately](#starting-gazebo-and-px4-separately) so that you can keep Gazebo Classic running and only re-launch PX4 when needed (quicker than restarting both).
|
||||
- Run the simulation in [Headless Mode](#headless-mode), which does not start the Gazebo Classic UI (this uses fewer resources and is much faster).
|
||||
|
||||
## Підйом у небо
|
||||
|
||||
The `make` commands above first build PX4, and then run it along with the Gazebo Classic simulator.
|
||||
|
||||
Після запуску PX4 запуститься оболонка PX4, як показано нижче.
|
||||
|
||||
```sh
|
||||
______ __ __ ___
|
||||
| ___ \ \ \ / / / |
|
||||
| |_/ / \ V / / /| |
|
||||
| __/ / \ / /_| |
|
||||
| | / /^\ \ \___ |
|
||||
\_| \/ \/ |_/
|
||||
|
||||
px4 starting.
|
||||
|
||||
INFO [px4] Calling startup script: /bin/sh etc/init.d-posix/rcS 0
|
||||
INFO [param] selected parameter default file eeprom/parameters_10016
|
||||
[param] Loaded: eeprom/parameters_10016
|
||||
INFO [dataman] Unknown restart, data manager file './dataman' size is 11798680 bytes
|
||||
INFO [simulator] Waiting for simulator to connect on TCP port 4560
|
||||
Gazebo multi-robot simulator, version 9.0.0
|
||||
Copyright (C) 2012 Open Source Robotics Foundation.
|
||||
Released under the Apache 2 License.
|
||||
http://gazebosim.org
|
||||
...
|
||||
INFO [ecl/EKF] 5188000: commencing GPS fusion
|
||||
```
|
||||
|
||||
Консоль буде виводити статус поки PX4 завантажує файли ініціалізації та параметрів для певного планера, чекати та підключатися до симулятора.
|
||||
Once there is an INFO print that [ecl/EKF] is `commencing GPS fusion` the vehicle is ready to arm.
|
||||
|
||||
:::info
|
||||
Right-clicking the quadrotor model allows to enable follow mode from the context menu, which is handy to keep it in view.
|
||||
:::
|
||||
|
||||

|
||||
|
||||
Ви можете підняти його у повітря надрукувавши:
|
||||
|
||||
```sh
|
||||
pxh> commander takeoff
|
||||
```
|
||||
|
||||
## Використання/Налаштування
|
||||
|
||||
Options that apply to all simulators are covered in the top level [Simulation](../simulation/index.md#sitl-simulation-environment) topic (some of these may be duplicated below).
|
||||
|
||||
### Імітація відмови датчика/обладнання
|
||||
|
||||
[Simulate Failsafes](../simulation/failsafes.md) explains how to trigger safety failsafes like GPS failure and battery drain.
|
||||
|
||||
### Режим без інтерфейсу
|
||||
|
||||
Gazebo Classic can be run in a _headless_ mode in which the Gazebo Classic UI is not launched.
|
||||
Цей режим запускається швидше та використовує менше системних ресурсів (тобто більш "легкий" спосіб запускати симуляцію).
|
||||
|
||||
Simply prefix the normal `make` command with `HEADLESS=1` as shown:
|
||||
|
||||
```sh
|
||||
HEADLESS=1 make px4_sitl gazebo-classic_plane
|
||||
```
|
||||
|
||||
<a id="custom_takeoff_location"></a>
|
||||
|
||||
### Встановлення власного місця зльоту
|
||||
|
||||
Місце зльоту в Gazebo Classic можна встановити використовуючи змінні середовища.
|
||||
This will override both the default takeoff location, and any value [set for the world](#set-world-location).
|
||||
|
||||
The variables to set are: `PX4_HOME_LAT`, `PX4_HOME_LON`, and `PX4_HOME_ALT`.
|
||||
|
||||
Наприклад:
|
||||
|
||||
```sh
|
||||
export PX4_HOME_LAT=28.452386
|
||||
export PX4_HOME_LON=-13.867138
|
||||
export PX4_HOME_ALT=28.5
|
||||
make px4_sitl gazebo-classic
|
||||
```
|
||||
|
||||
### Зміна швидкості симуляції
|
||||
|
||||
The simulation speed can be increased or decreased with respect to realtime using the environment variable `PX4_SIM_SPEED_FACTOR`.
|
||||
|
||||
To run at double real-time:
|
||||
|
||||
```sh
|
||||
PX4_SIM_SPEED_FACTOR=2 make px4_sitl_default gazebo-classic
|
||||
```
|
||||
|
||||
Запустити в половину реального часу:
|
||||
|
||||
```sh
|
||||
PX4_SIM_SPEED_FACTOR=0.5 make px4_sitl_default gazebo-classic
|
||||
```
|
||||
|
||||
To apply a factor to all SITL runs in the current session, use `EXPORT`:
|
||||
|
||||
```sh
|
||||
export PX4_SIM_SPEED_FACTOR=2
|
||||
make px4_sitl_default gazebo-classic
|
||||
```
|
||||
|
||||
### Зміна швидкості вітру
|
||||
|
||||
To simulate wind speed, add this plugin to your world file and set `windVelocityMean` in m/s (replace `SET_YOUR_WIND_SPEED` with your desired speed).
|
||||
If needed, adapt the `windVelocityMax` parameter so that it is greater than `windVelocityMean`:
|
||||
|
||||
```xml
|
||||
<plugin name='wind_plugin' filename='libgazebo_wind_plugin.so'>
|
||||
<frameId>base_link</frameId>
|
||||
<robotNamespace/>
|
||||
<windVelocityMean>SET_YOUR_WIND_SPEED</windVelocityMean>
|
||||
<windVelocityMax>20.0</windVelocityMax>
|
||||
<windVelocityVariance>0</windVelocityVariance>
|
||||
<windDirectionMean>0 1 0</windDirectionMean>
|
||||
<windDirectionVariance>0</windDirectionVariance>
|
||||
<windGustStart>0</windGustStart>
|
||||
<windGustDuration>0</windGustDuration>
|
||||
<windGustVelocityMean>0</windGustVelocityMean>
|
||||
<windGustVelocityMax>20.0</windGustVelocityMax>
|
||||
<windGustVelocityVariance>0</windGustVelocityVariance>
|
||||
<windGustDirectionMean>1 0 0</windGustDirectionMean>
|
||||
<windGustDirectionVariance>0</windGustDirectionVariance>
|
||||
<windPubTopic>world_wind</windPubTopic>
|
||||
</plugin>
|
||||
```
|
||||
|
||||
Напрямок вітру передається як вектор напрямку (за стандартною конвенцією ENU), який буде нормалізовано в плагіні gazebo.
|
||||
Додатково ви можете вказати відхилення швидкості вітру у (м/с)² та відхилення у напрямку на основі нормального розподілу, щоб додати випадковий фактор в симуляцію.
|
||||
Gust is internally handled in the same way as wind, with the slight difference that you can state start time and duration with the following two parameters `windGustStart` and `windGustDuration`.
|
||||
|
||||
You can see how this is done in [PX4/PX4-SITL_gazebo-classic/worlds/windy.world](https://github.com/PX4/PX4-SITL_gazebo-classic/blob/main/worlds/windy.world#L15-L31).
|
||||
|
||||
### Використання джойстика
|
||||
|
||||
Joystick and thumb-joystick support are supported through _QGroundControl_ ([setup instructions here](../simulation/index.md#joystick-gamepad-integration)).
|
||||
|
||||
### Підвищення ефективності сенсору відстані
|
||||
|
||||
The current default world is [PX4-Autopilot/Tools/simulation/gazebo-classic/sitl_gazebo-classic/worlds/**iris.world**](https://github.com/PX4/PX4-SITL_gazebo-classic/tree/main/worlds)), which uses a heightmap as ground.
|
||||
|
||||
Це може викликати труднощі під час використання датчика відстані.
|
||||
If there are unexpected results we recommend you change the model in **iris.model** from `uneven_ground` to `asphalt_plane`.
|
||||
|
||||
### Симуляція шуму GPS
|
||||
|
||||
Gazebo Classic може симулювати шум GPS подібний до того, який зазвичай можна знайти в реальних системах (в іншому випадку значення GPS що передаються будуть вільними від шуму або ідеальними).
|
||||
Це корисно, якщо ви працюєте над додатками, на які може вплинути шум GPS, наприклад точного позиціювання.
|
||||
|
||||
GPS noise is enabled if the target vehicle's SDF file contains a value for the `gpsNoise` element (i.e. it has the line: `<gpsNoise>true</gpsNoise>`).
|
||||
It is enabled by default in many vehicle SDF files: **solo.sdf**, **iris.sdf**, **standard_vtol.sdf**, **delta_wing.sdf**, **plane.sdf**, **typhoon_h480**, **tailsitter.sdf**.
|
||||
|
||||
Щоб увімкнути/вимкнути шум GPS:
|
||||
|
||||
1. Зберіть будь-яку ціль збірки gazebo, щоб згенерувати SDF файл (для всіх засобів).
|
||||
Наприклад:
|
||||
|
||||
```sh
|
||||
make px4_sitl gazebo-classic_iris
|
||||
```
|
||||
|
||||
:::tip
|
||||
The SDF files are not overwritten on subsequent builds.
|
||||
|
||||
:::
|
||||
|
||||
2. Open the SDF file for your target vehicle (e.g. **./Tools/simulation/gazebo-classic/sitl_gazebo-classic/models/iris/iris.sdf**).
|
||||
|
||||
3. Search for the `gpsNoise` element:
|
||||
|
||||
```xml
|
||||
<plugin name='gps_plugin' filename='libgazebo_gps_plugin.so'>
|
||||
<robotNamespace/>
|
||||
<gpsNoise>true</gpsNoise>
|
||||
</plugin>
|
||||
```
|
||||
|
||||
- Якщо він присутній, GPS включений.
|
||||
You can disable it by deleting the line: `<gpsNoise>true</gpsNoise>`
|
||||
- Якщо він відсутній, GPS вимкнено.
|
||||
You can enable it by adding the `gpsNoise` element to the `gps_plugin` section (as shown above).
|
||||
|
||||
Наступного разу, коли ви зберете/перезапустите Gazebo Classic він буде використовувати нове налаштування шуму GPS.
|
||||
|
||||
## Завантаження певного світу
|
||||
|
||||
PX4 supports a number of [Worlds](../sim_gazebo_classic/worlds.md), which are stored in [PX4-Autopilot/Tools/simulation/gazebo-classic/sitl_gazebo-classic/worlds](https://github.com/PX4/PX4-SITL_gazebo-classic/tree/main/worlds).
|
||||
By default Gazebo Classic displays a flat featureless plane, as defined in [empty.world](https://github.com/PX4/PX4-SITL_gazebo-classic/blob/main/worlds/empty.world).
|
||||
|
||||
Можна завантажити будь-який зі світів вказавши їх як завершальний параметр в налаштуваннях цілі збірки PX4.
|
||||
|
||||
For example, to load the _warehouse_ world, you can append it as shown:
|
||||
|
||||
```sh
|
||||
make px4_sitl_default gazebo-classic_plane_cam__warehouse
|
||||
```
|
||||
|
||||
:::info
|
||||
There are _two underscores_ after the model (`plane_cam`) indicating that the default debugger is used (none).
|
||||
See [Building the Code > PX4 Make Build Targets](../dev_setup/building_px4.md#px4-make-build-targets).
|
||||
:::
|
||||
|
||||
You can also specify the full path to a world to load using the `PX4_SITL_WORLD` environment variable.
|
||||
Це підходить при тестуванні нового світу, який ще не включений до PX4.
|
||||
|
||||
:::tip
|
||||
If the loaded world does not align with the map, you may need to [set the world location](#set-world-location).
|
||||
:::
|
||||
|
||||
## Встановлення розташування світу
|
||||
|
||||
Рухомий засіб відтворюється дуже близько до початкового положення моделі світу у певному симульованому GPS розташуванні.
|
||||
|
||||
:::info
|
||||
The vehicle is not spawned exactly at the Gazebo origin (0,0,0), but using a slight offset, which can highlight a number of common coding issues.
|
||||
:::
|
||||
|
||||
При використанні світу, що відтворює реальне місце (наприклад певний аеропорт) це може призвести до доволі наявної невідповідності між тим що показується у світі, що симулюється та тим, що показується на мапі наземної станції.
|
||||
Для подолання цієї проблеми ви можете встановити місце розташування початкового положення світу до GPS координат, де воно буде в "реальному житті".
|
||||
|
||||
:::info
|
||||
You can also set a [Custom Takeoff Location](#custom_takeoff_location) that does the same thing.
|
||||
Однак додавання розташування на мапу простіше (і воно все ще може бути змінене шляхом встановлення користувацького розташування при необхідності).
|
||||
:::
|
||||
|
||||
The location of the world is defined in the **.world** file by specifying the location of the origin using the `spherical_coordinates` tag.
|
||||
Щоб це було коректним, обов'язково треба вказати широту, довготу та висоту над рівнем моря.
|
||||
|
||||
An example can be found in the [sonoma_raceway.world](https://github.com/PX4/PX4-SITL_gazebo-classic/blob/main/worlds/sonoma_raceway.world):
|
||||
|
||||
```xml
|
||||
<spherical_coordinates>
|
||||
<surface_model>EARTH_WGS84</surface_model>
|
||||
<latitude_deg>38.161479</latitude_deg>
|
||||
<longitude_deg>-122.454630</longitude_deg>
|
||||
<elevation>488.0</elevation>
|
||||
</spherical_coordinates>
|
||||
```
|
||||
|
||||
You can test this by spawning a rover in the [Sonoma Raceway World](../sim_gazebo_classic/worlds.md#sonoma-raceway) using the following `make` command (note that spawning takes longer the first time as the model needs to be downloaded from the model database):
|
||||
|
||||
```sh
|
||||
make px4_sitl gazebo-classic_rover__sonoma_raceway
|
||||
```
|
||||
|
||||
У наведеному нижче відео видно, що розташування середовища збігається зі світом:
|
||||
|
||||
<lite-youtube videoid="-a2WWLni5do" title="Driving a simulated PX4 Rover in the Sonoma Raceway"/>
|
||||
|
||||
## Запуск Gazebo та PX4 окремо
|
||||
|
||||
Для розширених сеансів розробки можливо більш зручно запускати Gazebo Classic та PX4 окремо або навіть з IDE.
|
||||
|
||||
In addition to the existing cmake targets that run `sitl_run.sh` with parameters for px4 to load the correct model it creates a launcher targets named `px4_<mode>` that is a thin wrapper around original sitl px4 app.
|
||||
Ця тонка обгортка просто містить аргументи застосунку типу поточної робочої директорії та шляху до файлу моделі.
|
||||
|
||||
Щоб запустити Gazebo Classic та PX4 окремо:
|
||||
|
||||
- Run gazebo classic (or any other sim) server and client viewers via the terminal specifying an `_ide` variant:
|
||||
|
||||
```sh
|
||||
make px4_sitl gazebo-classic___ide
|
||||
```
|
||||
|
||||
або
|
||||
|
||||
```sh
|
||||
make px4_sitl gazebo-classic_iris_ide
|
||||
```
|
||||
|
||||
- In your IDE select `px4_<mode>` target you want to debug (e.g. `px4_iris`)
|
||||
|
||||
- Запустіть сеанс налагодження безпосередньо з IDE
|
||||
|
||||
Цей підхід суттєво зменшує час циклу налагодження, оскільки симулятор завжди працює у фоновому режимі та ви перезавантажуєте тільки процес px4, який дуже легкий.
|
||||
|
||||
## Симуляція камери спостереження
|
||||
|
||||
The _Gazebo Classic_ survey camera simulates a [MAVLink camera](https://mavlink.io/en/services/camera.html) that captures geotagged JPEG images and sends camera capture information to a connected ground station.
|
||||
Камера також підтримує відеотрансляцію.
|
||||
Вона може бути використана для перевірки захоплення камери, зокрема в політних завданнях спостереження.
|
||||
|
||||
The camera emits the [CAMERA_IMAGE_CAPTURED](https://mavlink.io/en/messages/common.html#CAMERA_IMAGE_CAPTURED) message every time an image is captured.
|
||||
The captured images are saved to: `PX4-Autopilot/build/px4_sitl_default/src/modules/simulation/simulator_mavlink/frames/DSC_n.jpg` (where _n_ starts as 00000 and is iterated by one on each capture).
|
||||
To simulate a plane with this camera:
|
||||
|
||||
```sh
|
||||
make px4_sitl_default gazebo-classic_plane_cam
|
||||
```
|
||||
|
||||
:::info
|
||||
The camera also supports/responds to the following MAVLink commands: [MAV_CMD_REQUEST_CAMERA_CAPTURE_STATUS](https://mavlink.io/en/messages/common.html#MAV_CMD_REQUEST_CAMERA_CAPTURE_STATUS), [MAV_CMD_REQUEST_STORAGE_INFORMATION](https://mavlink.io/en/messages/common.html#MAV_CMD_REQUEST_STORAGE_INFORMATION), [MAV_CMD_REQUEST_CAMERA_SETTINGS](https://mavlink.io/en/messages/common.html#MAV_CMD_REQUEST_CAMERA_SETTINGS), [MAV_CMD_REQUEST_CAMERA_INFORMATION](https://mavlink.io/en/messages/common.html#MAV_CMD_REQUEST_CAMERA_INFORMATION), [MAV_CMD_RESET_CAMERA_SETTINGS](https://mavlink.io/en/messages/common.html#MAV_CMD_RESET_CAMERA_SETTINGS), [MAV_CMD_STORAGE_FORMAT](https://mavlink.io/en/messages/common.html#MAV_CMD_STORAGE_FORMAT), [MAV_CMD_SET_CAMERA_ZOOM](https://mavlink.io/en/messages/common.html#MAV_CMD_SET_CAMERA_ZOOM), [MAV_CMD_IMAGE_START_CAPTURE](https://mavlink.io/en/messages/common.html#MAV_CMD_IMAGE_START_CAPTURE), [MAV_CMD_IMAGE_STOP_CAPTURE](https://mavlink.io/en/messages/common.html#MAV_CMD_IMAGE_STOP_CAPTURE), [MAV_CMD_REQUEST_VIDEO_STREAM_INFORMATION](https://mavlink.io/en/messages/common.html#MAV_CMD_REQUEST_VIDEO_STREAM_INFORMATION), [MAV_CMD_REQUEST_VIDEO_STREAM_STATUS](https://mavlink.io/en/messages/common.html#MAV_CMD_REQUEST_VIDEO_STREAM_STATUS), [MAV_CMD_SET_CAMERA_MODE](https://mavlink.io/en/messages/common.html#MAV_CMD_SET_CAMERA_MODE).
|
||||
:::
|
||||
|
||||
:::info
|
||||
The simulated camera is implemented in [PX4/PX4-SITL_gazebo-classic/main/src/gazebo_camera_manager_plugin.cpp](https://github.com/PX4/PX4-SITL_gazebo-classic/blob/main/src/gazebo_camera_manager_plugin.cpp).
|
||||
:::
|
||||
|
||||
## Simulated Depth Camera
|
||||
|
||||
The _Gazebo Classic_ [depth camera model](https://github.com/PX4/PX4-SITL_gazebo-classic/blob/main/models/depth_camera/depth_camera.sdf.jinja) simulates an Intel® RealSense™ D455 stereo depth camera using the [Openni Kinect plugin](https://classic.gazebosim.org/tutorials?tut=ros_gzplugins#OpenniKinect).
|
||||
|
||||
This publishes depth images and camera information on the `/camera/depth/image_raw` and `/camera/depth/camera_info` ROS topics respectively.
|
||||
|
||||
To use these images, you will need to install ROS or ROS 2.
|
||||
Note the warning at the top of this page about how to "avoid installation conflicts" when installing ROS and Gazebo.
|
||||
|
||||
You can simulate a quadrotor with a forward-facing depth camera:
|
||||
|
||||
```sh
|
||||
make px4_sitl gazebo-classic_iris_depth_camera
|
||||
```
|
||||
|
||||
or a quadrotor with a downward-facing depth camera:
|
||||
|
||||
```sh
|
||||
make px4_sitl gazebo-classic_iris_downward_depth_camera
|
||||
```
|
||||
|
||||
## Simulated Parachute/Flight Termination
|
||||
|
||||
_Gazebo Classic_ can be used to simulate deploying a [parachute](../peripherals/parachute.md) during [Flight Termination](../advanced_config/flight_termination.md) (flight termination is triggered by the PWM command that is simulated in _Gazebo Classic_).
|
||||
|
||||
The `if750a` target has a parachute attached to the vehicle.
|
||||
To simulate the vehicle, run the following command:
|
||||
|
||||
```sh
|
||||
make px4_sitl gazebo-classic_if750a
|
||||
```
|
||||
|
||||
To put the vehicle into flight termination state, you can force it to fail a [safety check](../config/safety.md) that has flight termination set as the failsafe action.
|
||||
For example, you could do this by forcing a [Geofence violation](../config/safety.md#geofence-failsafe).
|
||||
|
||||
Для додаткової інформації дивіться:
|
||||
|
||||
- [Flight Termination](../advanced_config/flight_termination.md)
|
||||
- [Parachute](../peripherals/parachute.md)
|
||||
- [Safety Configuration (Failsafes)](../config/safety.md)
|
||||
|
||||
## Video Streaming
|
||||
|
||||
PX4 SITL for Gazebo Classic supports UDP video streaming from a camera sensor attached to a simulated vehicle model.
|
||||
When streaming is enabled, you can connect to this stream from _QGroundControl_ (on UDP port 5600) and view video of the Gazebo Classic environment from the simulated vehicle - just as you would from a real camera.
|
||||
The video is streamed using a _gstreamer_ pipeline and can be enabled/disabled using a button in the Gazebo Classic UI.
|
||||
|
||||
The simulated camera sensor is supported/enabled on the following frames:
|
||||
|
||||
- [Typhoon H480](#typhoon_h480)
|
||||
|
||||
### Вимоги
|
||||
|
||||
_Gstreamer 1.0_ is required for video streaming.
|
||||
The required dependencies should already have been [installed when you set up Gazebo Classic](#installation) (they are included in the standard PX4 installation scripts/instructions for macOS and Ubuntu Linux).
|
||||
|
||||
:::info
|
||||
FYI only, the dependencies include: `gstreamer1.0-plugins-base`, `gstreamer1.0-plugins-good`, `gstreamer1.0-plugins-bad`, `gstreamer1.0-plugins-ugly`, `libgstreamer-plugins-base1.0-dev`.
|
||||
:::
|
||||
|
||||
### Start/Stop Video Streaming
|
||||
|
||||
Video streaming is automatically started when supported by the target vehicle.
|
||||
For example, to start streaming video on the Typhoon H480:
|
||||
|
||||
```sh
|
||||
make px4_sitl gazebo-classic_typhoon_h480
|
||||
```
|
||||
|
||||
Streaming can be paused/restarted using the Gazebo UI _Video ON/OFF_ button..
|
||||
|
||||

|
||||
|
||||
### How to View Gazebo Video
|
||||
|
||||
The easiest way to view the SITL/Gazebo Classic camera video stream is in _QGroundControl_.
|
||||
Simply open **Application Settings > General** and set **Video Source** to _UDP h.264 Video Stream_ and **UDP Port** to _5600_:
|
||||
|
||||

|
||||
|
||||
The video from Gazebo Classic should then display in _QGroundControl_ just as it would from a real camera.
|
||||
|
||||

|
||||
|
||||
:::info
|
||||
The Typhoon world is not very interesting.
|
||||
:::
|
||||
|
||||
It is also possible to view the video using the _Gstreamer Pipeline_.
|
||||
Simply enter the following terminal command:
|
||||
|
||||
```sh
|
||||
gst-launch-1.0 -v udpsrc port=5600 caps='application/x-rtp, media=(string)video, clock-rate=(int)90000, encoding-name=(string)H264' \
|
||||
! rtph264depay ! avdec_h264 ! videoconvert ! autovideosink fps-update-interval=1000 sync=false
|
||||
```
|
||||
|
||||
### Докладне ведення журналу
|
||||
|
||||
SITL fails silently when there is something wrong with the model.
|
||||
You can enable more verbose logging using `VERBOSE_SIM`, as shown:
|
||||
|
||||
```sh
|
||||
export VERBOSE_SIM=1
|
||||
make px4_sitl gazebo-classic
|
||||
```
|
||||
|
||||
або
|
||||
|
||||
```sh
|
||||
VERBOSE_SIM=1 make px4_sitl gazebo-classic
|
||||
```
|
||||
|
||||
## Lockstep
|
||||
|
||||
PX4 SITL and Gazebo-Classic have been set up to run in _lockstep_.
|
||||
What this means is that PX4 and the simulator run at the same speed, and therefore can react appropriately to sensor and actuator messages.
|
||||
Lockstep makes it possible to [change the simulation speed](#change-simulation-speed), and also to pause it in order to step through code.
|
||||
|
||||
#### Lockstep Sequence
|
||||
|
||||
Послідовність кроків для lockstep наступна:
|
||||
|
||||
1. The simulation sends a sensor message [HIL_SENSOR](https://mavlink.io/en/messages/common.html#HIL_SENSOR) including a timestamp `time_usec` to update the sensor state and time of PX4.
|
||||
2. PX4 receives this and does one iteration of state estimation, controls, etc. and eventually sends an actuator message [HIL_ACTUATOR_CONTROLS](https://mavlink.io/en/messages/common.html#HIL_ACTUATOR_CONTROLS).
|
||||
3. Симуляція чекає, поки не отримає повідомлення від приводу/двигуна, потім моделює фізику і обчислює наступне повідомлення від датчика, яке знову надсилається до PX4.
|
||||
|
||||
Система починається з "вільного ходу", під час якого симуляція надсилає повідомлення від датчиків, зокрема про час, і, таким чином, запускає PX4, доки він не ініціалізується і не надішле відповідне повідомлення від приводу.
|
||||
|
||||
#### Disabling Lockstep
|
||||
|
||||
Lockstep симуляцію можна вимкнути, якщо, наприклад, SITL потрібно використовувати з тренажером, який не підтримує цю функцію.
|
||||
У цьому випадку симулятор і PX4 використовують системний час хоста і не чекають один на одного.
|
||||
|
||||
To disable lockstep in:
|
||||
|
||||
- PX4, run `make px4_sitl_default boardconfig` and set the `BOARD_NOLOCKSTEP` "Force disable lockstep" symbol which is located under toolchain.
|
||||
- Gazebo Classic, edit [the model SDF file](https://github.com/PX4/PX4-SITL_gazebo-classic/blob/3062d287c322fabf1b41b8e33518eb449d4ac6ed/models/plane/plane.sdf#L449) and set `<enable_lockstep>false</enable_lockstep>`.
|
||||
|
||||
## Розширення та персоналізація
|
||||
|
||||
To extend or customize the simulation interface, edit the files in the `Tools/simulation/gazebo/sitl_gazebo` folder.
|
||||
The code is available on the [sitl_gazebo repository](https://github.com/PX4/PX4-SITL_gazebo) on Github.
|
||||
|
||||
:::info
|
||||
The build system enforces the correct GIT submodules, including the simulator.
|
||||
It will not overwrite changes in files in the directory.
|
||||
:::
|
||||
|
||||
## Подальша інформація
|
||||
|
||||
- [ROS with Gazebo Classic Simulation](../simulation/ros_interface.md)
|
||||
- [Gazebo Classic Octomap](../sim_gazebo_classic/octomap.md)
|
||||
Reference in New Issue
Block a user