mirror of
https://gitee.com/mirrors_PX4/PX4-Autopilot.git
synced 2026-10-25 10:53:33 +08:00
Move PX4 Guide source into /docs (#24490)
* Add vitepress tree

* Update existing workflows so they dont trigger on changes in the docs path

* Add nojekyll, package.json, LICENCE etc

* Add crowdin docs upload/download scripts

* Add docs flaw checker workflows

* Used docs prefix for docs workflows

* Crowdin obvious fixes

* ci: docs move to self hosted runner

runs on a beefy server for faster builds

Signed-off-by: Ramon Roche <mrpollo@gmail.com>

* ci: don't run build action for docs or ci changes

Signed-off-by: Ramon Roche <mrpollo@gmail.com>

* ci: update runners

Signed-off-by: Ramon Roche <mrpollo@gmail.com>

* Add docs/en

* Add docs assets and scripts

* Fix up editlinks to point to PX4 sources

* Download just the translations that are supported

* Add translation sources for zh, uk, ko

* Update latest tranlsation and uorb graphs

* update vitepress to latest

---------

Signed-off-by: Ramon Roche <mrpollo@gmail.com>
Co-authored-by: Ramon Roche <mrpollo@gmail.com>
This commit is contained in:
 Hamish Willee
co-authored by
Ramon Roche
Ramon Roche
parent
8e6d2ebe4a
commit
88d623bedb
@@ -0,0 +1,338 @@
|
||||
# Використання Vision або Motion Capture систем для Position Estimation
|
||||
|
||||
Системи візуальної інерційної одометрії (VIO) та захоплення руху (MoCap) дозволяють транспортним засобам здійснювати навігацію, коли джерело глобального позиціонування недоступне або ненадійне (наприклад, в приміщенні або під час прольоту під мостом. тощо).
|
||||
|
||||
Both VIO and MoCap determine a vehicle's _pose_ (position and attitude) from "visual" information.
|
||||
Основна відмінність між ними - перспектива кадру:
|
||||
|
||||
- VIO uses _onboard sensors_ to get pose data from the vehicle's perspective (see [egomotion](https://en.wikipedia.org/wiki/Visual_odometry#Egomotion)).
|
||||
- MoCap uses a system of _off-board cameras_ to get vehicle pose data in a 3D space (i.e. it is an external system that tells the vehicle its pose).
|
||||
|
||||
Дані про положення, отримані від обох типів систем, можуть бути використані для оновлення оцінки локального положення автопілота на базі PX4 (відносно локальної точки відліку), а також, за бажанням, можуть бути інтегровані в оцінку положення транспортного засобу. Крім того, якщо зовнішня система позиціонування також забезпечує вимірювання лінійної швидкості, її можна використовувати для покращення оцінки стану (об'єднання вимірювань лінійної швидкості підтримується лише EKF2).
|
||||
|
||||
This topic explains how to configure a PX4-based system to get data from MoCap/VIO systems (either via ROS or some other MAVLink system) and more specifically how to set up MoCap systems like VICON and Optitrack, and vision-based estimation systems like [ROVIO](https://github.com/ethz-asl/rovio), [SVO](https://github.com/uzh-rpg/rpg_svo) and [PTAM](https://github.com/ethz-asl/ethzasl_ptam)).
|
||||
|
||||
:::info
|
||||
The instructions differ depending on whether you are using the EKF2 or LPE estimator.
|
||||
:::
|
||||
|
||||
## Інтеграція PX4 з MAVLink
|
||||
|
||||
PX4 uses the following MAVLink messages for getting external position information, and maps them to [uORB topics](../middleware/uorb.md):
|
||||
|
||||
| MAVLink | uORB |
|
||||
| ------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------ | ------------------------- |
|
||||
| [VISION_POSITION_ESTIMATE](https://mavlink.io/en/messages/common.html#VISION_POSITION_ESTIMATE) | `vehicle_visual_odometry` |
|
||||
| [ODOMETRY](https://mavlink.io/en/messages/common.html#ODOMETRY) (`frame_id =` [MAV_FRAME_LOCAL_FRD](https://mavlink.io/en/messages/common.html#MAV_FRAME_LOCAL_FRD)) | `vehicle_visual_odometry` |
|
||||
| [ATT_POS_MOCAP](https://mavlink.io/en/messages/common.html#ATT_POS_MOCAP) | `vehicle_mocap_odometry` |
|
||||
| [ODOMETRY](https://mavlink.io/en/messages/common.html#ODOMETRY) (`frame_id =` [MAV_FRAME_MOCAP_NED](https://mavlink.io/en/messages/common.html#MAV_FRAME_MOCAP_NED)) | `vehicle_mocap_odometry` |
|
||||
|
||||
EKF2 only subscribes to `vehicle_visual_odometry` topics and can hence only process the first two messages
|
||||
(a MoCap system must generate these messages to work with EKF2). Повідомлення odometry є єдиним повідомленням, яке може також відправляти лінійні швидкості в PX4.
|
||||
Оцінювач LPE підписується на обидві теми, тому може обробляти всі вищезазначені повідомлення.
|
||||
|
||||
:::tip
|
||||
EKF2 is the default estimator used by PX4.
|
||||
Він краще протестований і підтримується, ніж LPE, і його слід використовувати за умовчанням.
|
||||
:::
|
||||
|
||||
Повідомлення повинні транслюватися з частотою між 30 Гц (якщо містять коваріанти) і 50 Гц.
|
||||
Якщо частота повідомлень занадто низька, EKF2 не буде обробляти повідомлення з зовнішнього візуального спостереження.
|
||||
|
||||
The following MAVLink "vision" messages are not currently supported by PX4:
|
||||
[GLOBAL_VISION_POSITION_ESTIMATE](https://mavlink.io/en/messages/common.html#GLOBAL_VISION_POSITION_ESTIMATE),
|
||||
[VISION_SPEED_ESTIMATE](https://mavlink.io/en/messages/common.html#VISION_SPEED_ESTIMATE),
|
||||
[VICON_POSITION_ESTIMATE](https://mavlink.io/en/messages/common.html#VICON_POSITION_ESTIMATE)
|
||||
|
||||
## Основні відмінності
|
||||
|
||||
PX4 uses FRD (X **F**orward, Y **R**ight and Z **D**own) for the local body frame as well for the reference frame. When using the heading of the magnetometer, the PX4 reference frame x axis will be aligned with north, so therefore it is called NED (X **N**orth, Y **E**ast, Z **D**own). Напрямок опорного каркасу оцінювача PX4 та напрямок зовнішньої оцінки положення в більшості випадків не збігаються.
|
||||
Therefore the reference frame of the external pose estimate is named differently, it is called [MAV_FRAME_LOCAL_FRD](https://mavlink.io/en/messages/common.html#MAV_FRAME_LOCAL_FRD).
|
||||
|
||||
Залежно від джерела вашого опорного каркасу, вам потрібно буде застосувати власне перетворення до оцінки положення перед надсиланням повідомлення MAVLink Vision/MoCap.
|
||||
Це необхідно для зміни орієнтації батьківського та дочірнього каркасу оцінки положення так, щоб вона відповідала конвенції PX4. Have a look at the MAVROS [_odom_ plugin](https://github.com/mavlink/mavros/blob/master/mavros_extras/src/plugins/odom.cpp) for the necessary transformations.
|
||||
|
||||
:::tip
|
||||
ROS users can find more detailed instructions below in [Reference Frames and ROS](#reference-frames-and-ros).
|
||||
:::
|
||||
|
||||
For example, if using the Optitrack framework the local frame has $x{}$ and $z{}$ on the horizontal plane (_x_ front and _z_ right) while _y_ axis is vertical and pointing up.
|
||||
Простий трюк полягає в тому, що обмінюються вісіми, щоб отримати конвенцію NED.
|
||||
|
||||
If `x_{mav}`, `y_{mav}` and `z_{mav}` are the coordinates that are sent through MAVLink as position feedback, then we obtain:
|
||||
|
||||
```
|
||||
x_{mav} = x_{mocap}
|
||||
y_{mav} = z_{mocap}
|
||||
z_{mav} = - y_{mocap}
|
||||
```
|
||||
|
||||
Regarding the orientation, keep the scalar part _w_ of the quaternion the same and swap the vector part _x_, _y_ and _z_ in the same way.
|
||||
Ви можете застосувати цей трюк у будь-якій системі - якщо вам потрібно отримати рамку NED, подивіться на вивід вашого MoCap та обміняйте вісі відповідно.
|
||||
|
||||
## Конфігурація та налаштування EKF2
|
||||
|
||||
Примітка: це короткий огляд.
|
||||
For more detailed information, check the [Using PX4's Navigation Filter (EKF2)](../advanced_config/tuning_the_ecl_ekf.md)
|
||||
|
||||
The following parameters must be set to use external position information with EKF2 (these can be set in _QGroundControl_ > **Vehicle Setup > Parameters > EKF2**).
|
||||
|
||||
| Параметр | Налаштування для Зовнішньої Оцінки Положення |
|
||||
| ------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------- | ------------------------------------------------------------------------------------------------------------------------------------------------------------------------ |
|
||||
| [EKF2_EV_CTRL](../advanced_config/parameter_reference.md#EKF2_EV_CTRL) | Set _horizontal position fusion_, _vertical vision fusion_, _velocity fusion_, and _yaw fusion_, according to your desired fusion model. |
|
||||
| [EKF2_HGT_REF](../advanced_config/parameter_reference.md#EKF2_HGT_REF) | Set to _Vision_ to use the vision as the reference source for altitude estimation. |
|
||||
| [EKF2_EV_DELAY](../advanced_config/parameter_reference.md#EKF2_EV_DELAY) | Встановіть різницю між міткою часу вимірювання та "фактичним" часом захоплення. For more information see [below](#tuning-EKF2_EV_DELAY). |
|
||||
| [EKF2_EV_POS_X](../advanced_config/parameter_reference.md#EKF2_EV_POS_X), [EKF2_EV_POS_Y](../advanced_config/parameter_reference.md#EKF2_EV_POS_Y), [EKF2_EV_POS_Z](../advanced_config/parameter_reference.md#EKF2_EV_POS_Z) | Встановіть положення візійного датчика (або маркерів MoCap) відносно тіла робота. |
|
||||
|
||||
You can also disable GNSS, baro and range finder fusion using [EKF2_GPS_CTRL](../advanced_config/parameter_reference.md#EKF2_GPS_CTRL), [EKF2_BARO_CTRL](../advanced_config/parameter_reference.md#EKF2_BARO_CTRL) and [EKF2_RNG_CTRL](../advanced_config/parameter_reference.md#EKF2_RNG_CTRL), respectively.
|
||||
|
||||
:::tip
|
||||
Reboot the flight controller in order for parameter changes to take effect.
|
||||
:::
|
||||
|
||||
<a id="tuning-EKF2_EV_DELAY"></a>
|
||||
|
||||
#### Налаштування EKF2_EV_DELAY
|
||||
|
||||
[EKF2_EV_DELAY](../advanced_config/parameter_reference.md#EKF2_EV_DELAY) is the _Vision Position Estimator delay relative to IMU measurements_.
|
||||
|
||||
Іншими словами, це різниця між міткою часу системи комп'ютерного зору та "фактичним" часом захоплення, який був би зафіксований годинником IMU ("базовим годинником" для EKF2).
|
||||
|
||||
Технічно цей параметр можна встановити на 0, якщо між комп'ютерами MoCap і (наприклад) ROS є правильне маркування часу (не тільки час прибуття) і синхронізація часу (наприклад, NTP).
|
||||
In reality, this needs some empirical tuning since delays in the entire MoCap->PX4 chain are very setup-specific.
|
||||
Рідко коли система налаштована з повністю синхронізованим ланцюжком!
|
||||
|
||||
Приблизну оцінку затримки можна отримати з логів, перевіривши зсув між частотами IMU та EV.
|
||||
To enable logging of EV rates set bit 7 (Computer Vision and Avoidance) of [SDLOG_PROFILE](../advanced_config/parameter_reference.md#SDLOG_PROFILE).
|
||||
|
||||

|
||||
|
||||
:::info
|
||||
A plot of external data vs. onboard estimate (as above) can be generated using [FlightPlot](../log/flight_log_analysis.md#flightplot) or similar flight analysis tools.
|
||||
At time of writing (July 2021) neither [Flight Review](../log/flight_log_analysis.md#flight-review-online-tool) nor [MAVGCL](../log/flight_log_analysis.md#mavgcl) support this functionality.
|
||||
:::
|
||||
|
||||
Значення можна додатково налаштувати, змінюючи параметр, щоб знайти значення, яке дає найнижчі інновації EKF під час динамічних маневрів.
|
||||
|
||||
## LPE Конфігурація/Налаштування
|
||||
|
||||
You will first need to [switch to the LPE estimator](../advanced/switching_state_estimators.md) by setting the following parameters: [LPE_EN](../advanced_config/parameter_reference.md#LPE_EN) (1), [EKF2_EN](../advanced_config/parameter_reference.md#EKF2_EN) (0), [ATT_EN](../advanced_config/parameter_reference.md#ATT_EN) (0).
|
||||
|
||||
:::info
|
||||
If targeting `px4_fmu-v2` hardware you will also need to use a firmware version that includes the LPE module (firmware for other FMU-series hardware includes both LPE and EKF).
|
||||
The LPE version can be found in the zip file for each PX4 release or it can be built from source using the build command `make px4_fmu-v2_lpe`.
|
||||
See [Building the Code](../dev_setup/building_px4.md) for more details.
|
||||
:::
|
||||
|
||||
### Увімкнення зовнішнього введення позиції
|
||||
|
||||
The following parameters must be set to use external position information with LPE (these can be set in _QGroundControl_ > **Vehicle Setup > Parameters > Local Position Estimator**).
|
||||
|
||||
| Параметр | Налаштування для Зовнішньої Оцінки Положення |
|
||||
| --------------------------------------------------------------------------------------------------------------------------------------- | ------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------- |
|
||||
| [LPE_FUSION](../advanced_config/parameter_reference.md#LPE_FUSION) | Vision integration is enabled if _fuse vision position_ is checked (it is enabled by default). |
|
||||
| [ATT_EXT_HDG_M](../advanced_config/parameter_reference.md#ATT_EXT_HDG_M) | Встановіть значення 1 або 2, щоб увімкнути інтеграцію зовнішніх заголовків. Встановлення значення 1 призведе до використання зору, тоді як 2 увімкне використання заголовків MoCap. |
|
||||
|
||||
### Вимкнення Barometer Fusion
|
||||
|
||||
Якщо високоточна висота вже доступна з інформації VIO або MoCap, може бути корисно вимкнути корекцію баро в LPE, щоб зменшити дрейф по осі Z.
|
||||
|
||||
This can be done by in _QGroundControl_ by unchecking the _fuse baro_ option in the [LPE_FUSION](../advanced_config/parameter_reference.md#LPE_FUSION) parameter.
|
||||
|
||||
### Параметри налаштування шуму
|
||||
|
||||
If your vision or MoCap data is highly accurate, and you just want the estimator to track it tightly, you should reduce the standard deviation parameters: [LPE_VIS_XY](../advanced_config/parameter_reference.md#LPE_VIS_XY) and [LPE_VIS_Z](../advanced_config/parameter_reference.md#LPE_VIS_Z) (for VIO) or [LPE_VIC_P](../advanced_config/parameter_reference.md#LPE_VIC_P) (for MoCap).
|
||||
Зменшення їх призведе до того, що оцінювач буде більше довіряти вхідній оцінці положення.
|
||||
Можливо, вам доведеться встановити їх нижче допустимого мінімуму та ввімкнути примусове збереження.
|
||||
|
||||
:::tip
|
||||
If performance is still poor, try increasing the [LPE_PN_V](../advanced_config/parameter_reference.md#LPE_PN_V) parameter.
|
||||
Це змусить оцінювача більше довіряти вимірюванням під час оцінювання швидкості.
|
||||
:::
|
||||
|
||||
## Увімкнення автоматичних режимів з локальним розташуванням
|
||||
|
||||
All PX4 automatic flight modes (such as [Mission](../flight_modes_mc/mission.md), [Return](../flight_modes_mc/return.md), [Land](../flight_modes_mc/land.md), [Hold](../flight_modes_mc/land.md), [Orbit](../flight_modes_mc/orbit.md))) require a _global_ position estimate, which would normally come from a GPS/GNSS system.
|
||||
|
||||
Systems that only have a _local_ position estimate (from MOCAP, VIO, or similar) can use the [SET_GPS_GLOBAL_ORIGIN](https://mavlink.io/en/messages/common.html#SET_GPS_GLOBAL_ORIGIN) MAVLink message to set the origin of the EKF to a particular global location.
|
||||
Після цього EKF надасть оцінку глобального положення на основі походження та локального положення у просторі.
|
||||
|
||||
Це може бути використано при плануванні та виконанні місій у приміщенні, для встановлення місцевої точки повернення тощо.
|
||||
|
||||
## Робота з ROS
|
||||
|
||||
ROS is not _required_ for supplying external pose information, but is highly recommended as it already comes with good integrations with VIO and MoCap systems.
|
||||
PX4 вже мають бути налаштовані як вище.
|
||||
|
||||
### Отримання даних про позицію в ROS
|
||||
|
||||
Системи VIO та MoCap мають різні способи отримання даних про положення, а також власні налаштування та теми.
|
||||
|
||||
The setup for specific systems is covered [below](#setup_specific_systems).
|
||||
Для інших систем зверніться до документації з налаштування виробника.
|
||||
|
||||
<a id="relaying_pose_data_to_px4"></a>
|
||||
|
||||
### Передача даних про позицію до PX4
|
||||
|
||||
MAVROS має плагіни для передачі візуальної оцінки з системи VIO або MoCap за допомогою наступних пайплайнів:
|
||||
|
||||
| ROS | MAVLink | uORB |
|
||||
| ----------------------------------------------------------------------------------------- | ------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------ | ------------------------- |
|
||||
| /mavros/vision_pose/pose | [VISION_POSITION_ESTIMATE](https://mavlink.io/en/messages/common.html#VISION_POSITION_ESTIMATE) | `vehicle_visual_odometry` |
|
||||
| /mavros/odometry/out (`frame_id = odom`, `child_frame_id = base_link`) | [ODOMETRY](https://mavlink.io/en/messages/common.html#ODOMETRY) (`frame_id =` [MAV_FRAME_LOCAL_FRD](https://mavlink.io/en/messages/common.html#MAV_FRAME_LOCAL_FRD)) | `vehicle_visual_odometry` |
|
||||
| /mavros/mocap/pose | [ATT_POS_MOCAP](https://mavlink.io/en/messages/common.html#ATT_POS_MOCAP) | `vehicle_mocap_odometry` |
|
||||
| /mavros/odometry/out (`frame_id = odom`, `child_frame_id = base_link`) | [ODOMETRY](https://mavlink.io/en/messages/common.html#ODOMETRY) (`frame_id =` [MAV_FRAME_LOCAL_FRD](https://mavlink.io/en/messages/common.html#MAV_FRAME_LOCAL_FRD)) | `vehicle_mocap_odometry` |
|
||||
|
||||
Ви можете використовувати будь-який з наведених вище пайплайнів за допомогою LPE.
|
||||
|
||||
Якщо ви працюєте з EKF2, підтримуються лише "vision" пайплайни.
|
||||
To use MoCap data with EKF2 you will have to [remap](http://wiki.ros.org/roslaunch/XML/remap) the pose topic that you get from MoCap:
|
||||
|
||||
- MoCap ROS topics of type `geometry_msgs/PoseStamped` or `geometry_msgs/PoseWithCovarianceStamped` must be remapped to `/mavros/vision_pose/pose`.
|
||||
The `geometry_msgs/PoseStamped` topic is most common as MoCap doesn't usually have associated covariances to the data.
|
||||
- If you get data through a `nav_msgs/Odometry` ROS message then you will need to remap it to `/mavros/odometry/out`, making sure to update the `frame_id` and `child_frame_id` accordingly.
|
||||
- The odometry frames `frame_id = odom`, `child_frame_id = base_link` can be changed by updating the file in `mavros/launch/px4_config.yaml`. However, the current version of mavros (`1.3.0`) needs to be able to use the tf tree to find a transform from `frame_id` to the hardcoded frame `odom_ned`. The same applies to the `child_frame_id`, which needs to be connected in the tf tree to the hardcoded frame `base_link_frd`. If you are using mavros `1.2.0` and you didn't update the file `mavros/launch/px4_config.yaml`, then you can safely use the odometry frames `frame_id = odom`, `child_frame_id = base_link` without much worry.
|
||||
- Note that if you are sending odometry data to px4 using `child_frame_id = base_link`, then you need to make sure that the `twist` portion of the `nav_msgs/Odometry` message is **expressed in body frame**, **not in inertial frame!!!!!**.
|
||||
|
||||
### Референсні системи координат та ROS
|
||||
|
||||
Локальна/світова та світова системи координат, що використовуються в ROS та PX4, відрізняються.
|
||||
|
||||
| Frame | PX4 | ROS |
|
||||
| ----- | ------------------------------------------------------------------- | -------------------------------------------------------------------------------------------------------- |
|
||||
| Body | FRD (X **F**orward, Y **R**ight, Z **D**own) | FLU (X **F**orward, Y **L**eft, Z **U**p), usually named `base_link` |
|
||||
| World | FRD or NED (X **N**orth, Y **E**ast, Z **D**own) | FLU or ENU (X **E**ast, Y **N**orth, Z **U**p), with the naming being `odom` or `map` |
|
||||
|
||||
:::tip
|
||||
See [REP105: Coordinate Frames for Mobile Platforms](http://www.ros.org/reps/rep-0105.html) for more information about ROS frames.
|
||||
:::
|
||||
|
||||
Обидві системи координат показані на зображенні нижче (FRD зліва / FLU справа).
|
||||
|
||||

|
||||
|
||||
З EKF2 при використанні зовнішньої оцінки напрямку магнітного північ може бути або ігноруватися, або зміщення напрямку до магнітного північного може бути розраховано та скомпенсовано. Depending on your choice the yaw angle is given with respect to either magnetic north or local _x_.
|
||||
|
||||
:::info
|
||||
When creating the rigid body in the MoCap software, remember to first align the robot's local _x_ axis with the world _x_ axis otherwise the yaw estimate will have an offset. Це може призупинити правильну роботу злиття зовнішньої оцінки позиції.
|
||||
Кут крену повинен дорівнювати нулю, коли тіло та опорна система вирівнюються.
|
||||
:::
|
||||
|
||||
Використовуючи MAVROS, ця операція є простою.
|
||||
ROS використовує фрейми ENU як конвенцію, тому зворотний зв'язок щодо позиції повинен бути наданий в ENU.
|
||||
If you have an Optitrack system you can use [mocap_optitrack](https://github.com/ros-drivers/mocap_optitrack) node which streams the object pose on a ROS topic already in ENU.
|
||||
With a remapping you can directly publish it on `mocap_pose_estimate` as it is without any transformation and MAVROS will take care of NED conversions.
|
||||
|
||||
Плагін MAVROS відомий тим, що спрощує роботу з координатними рамками.
|
||||
Він використовує пакет tf ROS. Ваш зовнішній система позиціонування може мати зовсім іншу конвенцію рамки, яка не відповідає конвенції PX4.
|
||||
Корпусна рама зовнішньої оцінки позиції може залежати від того, як ви встановите корпусну раму в програмному забезпеченні MOCAP або від того, як ви встановите сенсор VIO на дрона.
|
||||
Плагін відомостей MAVROS потребує знання, як дитяча рамка зовнішньої позиції орієнтована відносно рамки тіла FRD або FLU повітряного судна, відомої за допомогою MAVROS.
|
||||
Отже, вам потрібно додати зовнішню позу тіла до дерева tf. Це можна зробити, включивши адаптовану версію наступного рядка до вашого ROS-файлу запуску.
|
||||
|
||||
```
|
||||
<node pkg="tf" type="static_transform_publisher" name="tf_baseLink_externalPoseChildFrame"
|
||||
args="0 0 0 <yaw> <pitch> <roll> base_link <external_pose_child_frame> 1000"/>
|
||||
```
|
||||
|
||||
Make sure that you change the values of yaw, pitch and roll such that it properly attaches the external pose's body frame to the `base_link` or `base_link_frd`.
|
||||
Have a look at the [tf package](http://wiki.ros.org/tf#static_transform_publisher) for further help on how to specify the transformation between the frames.
|
||||
Ви можете використовувати rviz, щоб перевірити, чи ви правильно прикріпили рамку. The name of the `external_pose_child_frame` has to match the child_frame_id of your `nav_msgs/Odometry` message.
|
||||
Те ж саме стосується і для опорної рамки зовнішньої позиції. You have to attach the reference frame of the external pose as child to either the `odom` or `odom_frd` frame. Адаптуйте тому відповідно кодовий рядок.
|
||||
|
||||
```
|
||||
<node pkg="tf" type="static_transform_publisher" name="tf_odom_externalPoseParentFrame"
|
||||
args="0 0 0 <yaw> <pitch> <roll> odom <external_pose_parent_frame> 1000"/>
|
||||
```
|
||||
|
||||
If the reference frame has the z axis pointing upwards you can attached it without any rotation (yaw=0, pitch=0, roll=0) to the `odom` frame.
|
||||
The name of `external_pose_parent_frame` has to match the frame_id of the odometry message.
|
||||
|
||||
:::info
|
||||
When using the MAVROS _odom_ plugin, it is important that no other node is publishing a transform between the external pose's reference and child frame.
|
||||
This might break the _tf_ tree.
|
||||
:::
|
||||
|
||||
<a id="setup_specific_systems"></a>
|
||||
|
||||
## Конкретні налаштування системи
|
||||
|
||||
### OptiTrack MoCap
|
||||
|
||||
The following steps explain how to feed position estimates from an [OptiTrack](https://optitrack.com/motion-capture-robotics/) system to PX4.
|
||||
Припускається, що система MoCap налаштована.
|
||||
See [this video](https://www.youtube.com/watch?v=cNZaFEghTBU) for a tutorial on the calibration process.
|
||||
|
||||
#### Steps on the _Motive_ MoCap software
|
||||
|
||||
- Align your robot's forward direction with the [system +x-axis](https://v20.wiki.optitrack.com/index.php?title=Template:Coordinate_System)
|
||||
- [Define a rigid body in the Motive software](https://www.youtube.com/watch?v=1e6Qqxqe-k0). Give the robot a name that does not contain spaces, e.g. `robot1` instead of `Rigidbody 1`
|
||||
- [Enable Frame Broadacst and VRPN streaming](https://www.youtube.com/watch?v=yYRNG58zPFo)
|
||||
- Встановіть вісь Up на ось Z (за замовчуванням - Y)
|
||||
|
||||
#### Отримання даних про позицію в ROS
|
||||
|
||||
- Install the `vrpn_client_ros` package
|
||||
- Ви можете отримати позу кожного жорсткого тіла на окрему тему, запустивши
|
||||
```sh
|
||||
roslaunch vrpn_client_ros sample.launch server:=<mocap machine ip>
|
||||
```
|
||||
|
||||
If you named the rigidbody as `robot1`, you will get a topic like `/vrpn_client_node/robot1/pose`
|
||||
|
||||
#### Передача / перенаправлення даних про позу
|
||||
|
||||
MAVROS provides a plugin to relay pose data published on `/mavros/vision_pose/pose` to PX4.
|
||||
Assuming that MAVROS is running, you just need to **remap** the pose topic that you get from MoCap `/vrpn_client_node/<rigid_body_name>/pose` directly to `/mavros/vision_pose/pose`.
|
||||
Note that there is also a `mocap` topic that MAVROS provides to feed `ATT_POS_MOCAP` to PX4, but it is not applicable for EKF2.
|
||||
Однак, це застосовується з LPE.
|
||||
|
||||
:::info
|
||||
Remapping pose topics is covered above [Relaying pose data to PX4](#relaying_pose_data_to_px4) (`/vrpn_client_node/<rigid_body_name>/pose` is of type `geometry_msgs/PoseStamped`).
|
||||
:::
|
||||
|
||||
Припускаючи, що ви налаштували параметри EKF2, як описано вище, PX4 тепер встановлений і об'єднує дані MoCap.
|
||||
|
||||
Ви тепер готові перейти до першого політ.
|
||||
|
||||
## Перший політ
|
||||
|
||||
Після налаштування однієї з (специфічних) систем, описаних вище, ви повинні бути готові до тесту.
|
||||
Інструкції нижче показують, як це зробити для систем MoCap та VIO
|
||||
|
||||
### Перевірте зовнішню оцінку
|
||||
|
||||
Перед першим польотом обов'язково виконайте наступні перевірки:
|
||||
|
||||
- Set the PX4 parameter `MAV_ODOM_LP` to 1.
|
||||
PX4 will then stream back the received external pose as MAVLink [ODOMETRY](https://mavlink.io/en/messages/common.html#ODOMETRY) messages.
|
||||
- You can check these MAVLink messages with the _QGroundControl_ [MAVLink Inspector](https://docs.qgroundcontrol.com/master/en/qgc-user-guide/analyze_view/mavlink_inspector.html)
|
||||
In order to do this, yaw the vehicle until the quaternion of the `ODOMETRY` message is very close to a unit quaternion. (w=1, x=y=z=0)
|
||||
- На цьому етапі корпус виробу зорієнтований у відповідності з ориєнтацією відносно зовнішньої системи координат.
|
||||
Якщо вам не вдається отримати кватерніон, близький до одиничного, без обертання або нахилу вашого літака, це, ймовірно, означає, що ваша рама все ще має зміщення нахилу або кочування.
|
||||
У цьому випадку не продовжуйте і перевірте знову свої координатні рамки.
|
||||
- Після зорієнтування ви можете підняти літак з землі, і ви маєте бачити, як координата z позиції зменшується.
|
||||
Переміщення засобу в напрямку вперед повинно збільшити координату X.
|
||||
Під час руху транспортного засобу вправо слід збільшувати координату y.
|
||||
У разі, якщо ви також надсилаєте лінійні швидкості зовнішньої системи позиціонування, вам також слід перевірити лінійні швидкості.
|
||||
Check that the linear velocities are in expressed in the _FRD_ body frame reference frame.
|
||||
- Set the PX4 parameter `MAV_ODOM_LP` back to 0. PX4 припинить передавати це повідомлення назад.
|
||||
|
||||
Якщо ці кроки є послідовними, ви можете спробувати свій перший польот.
|
||||
|
||||
Покладіть робота на землю і почніть передавати зворотний зв'язок MoCap.
|
||||
Потягніть палицю газу вниз і зберметизуйте двигуни.
|
||||
|
||||
На цьому етапі, зліва палиця на найнижчому положенні, перейдіть у режим позиціонного контролю.
|
||||
Ви повинні побачити зелену лампочку.
|
||||
Зелена лампочка свідчить про те, що доступний зворотний зв'язок позиції, і позиційний контроль активований.
|
||||
|
||||
Помістіть лівий джойстик в середину, це зона мертвої зони.
|
||||
З цим значенням палиці робот підтримує свою висоту;
|
||||
підняття палиці збільшить висоту посилки, тоді як зниження значення зменшить її.
|
||||
Те ж саме для правої палиці по x та y.
|
||||
|
||||
Збільште значення лівої палиці, і робот злетить,
|
||||
поверніть його назад у середину праворуч після цього. Перевірте, чи він може утримати своє положення.
|
||||
|
||||
If it works, you may want to set up an [offboard](offboard_control.md) experiment by sending position-setpoint from a remote ground station.
|
||||
@@ -0,0 +1 @@
|
||||
<Redirect to="../ros2/" />
|
||||
@@ -0,0 +1,367 @@
|
||||
# Надсилання довільних повідомлень з MAVROS до PX4
|
||||
|
||||
:::warning
|
||||
This article has been tested against:
|
||||
|
||||
- **Ubuntu:** 20.04
|
||||
- **ROS:** Noetic
|
||||
- **PX4 Firmware:** v1.13
|
||||
|
||||
Однак, ці кроки досить загальні, і тому вони повинні працювати з іншими версіями та мінімальні зміни або не робити ніяких змін.
|
||||
:::
|
||||
|
||||
<!-- Content reproduced with permission from @JoonmoAhn in https://github.com/JoonmoAhn/Sending-Custom-Message-from-MAVROS-to-PX4/issues/1 -->
|
||||
|
||||
## Встановлення MAVROS
|
||||
|
||||
Follow _Source Installation_ instructions from [mavlink/mavros](https://github.com/mavlink/mavros/blob/master/mavros/index.md) to install "ROS Kinetic".
|
||||
|
||||
## MAVROS
|
||||
|
||||
1. We start by creating a new MAVROS plugin, in this example named **keyboard_command.cpp** (in **workspace/src/mavros/mavros_extras/src/plugins**) by using the code below:
|
||||
|
||||
The code subscribes a 'char' message from ROS topic `/mavros/keyboard_command/keyboard_sub` and sends it as a MAVLink message.
|
||||
|
||||
```c
|
||||
#include <mavros/mavros_plugin.h>
|
||||
#include <pluginlib/class_list_macros.h>
|
||||
#include <iostream>
|
||||
#include <std_msgs/Char.h>
|
||||
|
||||
namespace mavros {
|
||||
namespace extra_plugins{
|
||||
|
||||
class KeyboardCommandPlugin : public plugin::PluginBase {
|
||||
public:
|
||||
KeyboardCommandPlugin() : PluginBase(),
|
||||
nh("~keyboard_command")
|
||||
|
||||
{ };
|
||||
|
||||
void initialize(UAS &uas_)
|
||||
{
|
||||
PluginBase::initialize(uas_);
|
||||
keyboard_sub = nh.subscribe("keyboard_sub", 10, &KeyboardCommandPlugin::keyboard_cb, this);
|
||||
};
|
||||
|
||||
Subscriptions get_subscriptions()
|
||||
{
|
||||
return {/* RX disabled */ };
|
||||
}
|
||||
|
||||
private:
|
||||
ros::NodeHandle nh;
|
||||
ros::Subscriber keyboard_sub;
|
||||
|
||||
void keyboard_cb(const std_msgs::Char::ConstPtr &req)
|
||||
{
|
||||
std::cout << "Got Char : " << req->data << std::endl;
|
||||
mavlink::common::msg::KEY_COMMAND kc {};
|
||||
kc.command = req->data;
|
||||
UAS_FCU(m_uas)->send_message_ignore_drop(kc);
|
||||
}
|
||||
};
|
||||
} // namespace extra_plugins
|
||||
} // namespace mavros
|
||||
|
||||
PLUGINLIB_EXPORT_CLASS(mavros::extra_plugins::KeyboardCommandPlugin, mavros::plugin::PluginBase)
|
||||
```
|
||||
|
||||
2. Edit **mavros_plugins.xml** (in **workspace/src/mavros/mavros_extras**) and add the following lines:
|
||||
```xml
|
||||
<class name="keyboard_command" type="mavros::extra_plugins::KeyboardCommandPlugin" base_class_type="mavros::plugin::PluginBase">
|
||||
<description>Accepts keyboard command.</description>
|
||||
</class>
|
||||
```
|
||||
|
||||
3. Edit **CMakeLists.txt** (in **workspace/src/mavros/mavros_extras**) and add the following line in `add_library`.
|
||||
```cmake
|
||||
add_library(
|
||||
...
|
||||
src/plugins/keyboard_command.cpp
|
||||
)
|
||||
```
|
||||
|
||||
4. Inside **common.xml** in (**workspace/src/mavlink/message_definitions/v1.0**), copy the following lines to add your MAVLink message:
|
||||
```xml
|
||||
...
|
||||
<message id="229" name="KEY_COMMAND">
|
||||
<description>Keyboard char command.</description>
|
||||
<field type="char" name="command"> </field>
|
||||
</message>
|
||||
...
|
||||
```
|
||||
|
||||
## Зміни PX4
|
||||
|
||||
1. Inside **common.xml** (in **PX4-Autopilot/src/modules/mavlink/mavlink/message_definitions/v1.0**), add your MAVLink message as following (same procedure as for MAVROS section above):
|
||||
|
||||
```xml
|
||||
...
|
||||
<message id="229" name="KEY_COMMAND">
|
||||
<description>Keyboard char command.</description>
|
||||
<field type="char" name="command"> </field>
|
||||
</message>
|
||||
...
|
||||
```
|
||||
|
||||
:::warning
|
||||
Make sure that the **common.xml** files in the following directories are exactly the same:
|
||||
|
||||
- `PX4-Autopilot/src/modules/mavlink/mavlink/message_definitions/v1.0`
|
||||
- `workspace/src/mavlink/message_definitions/v1.0`
|
||||
are exactly the same.
|
||||
|
||||
:::
|
||||
|
||||
2. Make your own uORB message file **key_command.msg** in (PX4-Autopilot/msg). У цьому прикладі файл "key_command.msg" містить лише код:
|
||||
|
||||
```
|
||||
uint64 timestamp # time since system start (microseconds)
|
||||
char cmd
|
||||
```
|
||||
|
||||
Then, in **CMakeLists.txt** (in **PX4-Autopilot/msg**), include:
|
||||
|
||||
```cmake
|
||||
set(
|
||||
...
|
||||
key_command.msg
|
||||
)
|
||||
```
|
||||
|
||||
3. Edit **mavlink_receiver.h** (in **PX4-Autopilot/src/modules/mavlink**)
|
||||
|
||||
```cpp
|
||||
...
|
||||
#include <uORB/topics/key_command.h>
|
||||
...
|
||||
class MavlinkReceiver
|
||||
{
|
||||
...
|
||||
private:
|
||||
void handle_message_key_command(mavlink_message_t *msg);
|
||||
...
|
||||
orb_advert_t _key_command_pub{nullptr};
|
||||
}
|
||||
```
|
||||
|
||||
4. Edit **mavlink_receiver.cpp** (in **PX4-Autopilot/src/modules/mavlink**).
|
||||
Саме тут PX4 отримує повідомлення MAVLink від ROS, і публікує його як тему uORB.
|
||||
```cpp
|
||||
...
|
||||
void MavlinkReceiver::handle_message(mavlink_message_t *msg)
|
||||
{
|
||||
...
|
||||
case MAVLINK_MSG_ID_KEY_COMMAND:
|
||||
handle_message_key_command(msg);
|
||||
break;
|
||||
...
|
||||
}
|
||||
...
|
||||
void
|
||||
MavlinkReceiver::handle_message_key_command(mavlink_message_t *msg)
|
||||
{
|
||||
mavlink_key_command_t man;
|
||||
mavlink_msg_key_command_decode(msg, &man);
|
||||
|
||||
struct key_command_s key = {};
|
||||
|
||||
key.timestamp = hrt_absolute_time();
|
||||
key.cmd = man.command;
|
||||
|
||||
if (_key_command_pub == nullptr) {
|
||||
_key_command_pub = orb_advertise(ORB_ID(key_command), &key);
|
||||
|
||||
} else {
|
||||
orb_publish(ORB_ID(key_command), _key_command_pub, &key);
|
||||
}
|
||||
}
|
||||
```
|
||||
|
||||
5. Створіть власну підписку на тему uORB так само, як і будь-який інший приклад модуля підписки.
|
||||
Для цього прикладу створимо модель у (/PX4-Autopilot/src/modules/key_receiver).
|
||||
In this directory, create three files **CMakeLists.txt**, **key_receiver.cpp**, **Kconfig**
|
||||
Each one looks like the following.
|
||||
|
||||
-CMakeLists.txt
|
||||
|
||||
```cmake
|
||||
px4_add_module(
|
||||
MODULE modules__key_receiver
|
||||
MAIN key_receiver
|
||||
STACK_MAIN 2500
|
||||
STACK_MAX 4000
|
||||
SRCS
|
||||
key_receiver.cpp
|
||||
DEPENDS
|
||||
|
||||
)
|
||||
```
|
||||
|
||||
-key_receiver.cpp
|
||||
|
||||
```
|
||||
#include <px4_platform_common/px4_config.h>
|
||||
#include <px4_platform_common/tasks.h>
|
||||
#include <px4_platform_common/posix.h>
|
||||
#include <unistd.h>
|
||||
#include <stdio.h>
|
||||
#include <poll.h>
|
||||
#include <string.h>
|
||||
#include <math.h>
|
||||
|
||||
#include <uORB/uORB.h>
|
||||
#include <uORB/topics/key_command.h>
|
||||
|
||||
extern "C" __EXPORT int key_receiver_main(int argc, char **argv);
|
||||
|
||||
int key_receiver_main(int argc, char **argv)
|
||||
{
|
||||
int key_sub_fd = orb_subscribe(ORB_ID(key_command));
|
||||
orb_set_interval(key_sub_fd, 200); // limit the update rate to 200ms
|
||||
|
||||
px4_pollfd_struct_t fds[] = {
|
||||
{ .fd = key_sub_fd, .events = POLLIN },
|
||||
};
|
||||
|
||||
int error_counter = 0;
|
||||
|
||||
for (int i = 0; i < 10; i++)
|
||||
{
|
||||
int poll_ret = px4_poll(fds, 1, 1000);
|
||||
|
||||
if (poll_ret == 0)
|
||||
{
|
||||
PX4_ERR("Got no data within a second");
|
||||
}
|
||||
|
||||
else if (poll_ret < 0)
|
||||
{
|
||||
if (error_counter < 10 || error_counter % 50 == 0)
|
||||
{
|
||||
PX4_ERR("ERROR return value from poll(): %d", poll_ret);
|
||||
}
|
||||
|
||||
error_counter++;
|
||||
}
|
||||
|
||||
else
|
||||
{
|
||||
if (fds[0].revents & POLLIN)
|
||||
{
|
||||
struct key_command_s input;
|
||||
orb_copy(ORB_ID(key_command), key_sub_fd, &input);
|
||||
PX4_INFO("Received Char : %c", input.cmd);
|
||||
}
|
||||
}
|
||||
}
|
||||
return 0;
|
||||
}
|
||||
```
|
||||
|
||||
-Kconfig
|
||||
|
||||
```
|
||||
menuconfig MODULES_KEY_RECEIVER
|
||||
bool "key_receiver"
|
||||
default n
|
||||
---help---
|
||||
Enable support for key_receiver
|
||||
|
||||
```
|
||||
|
||||
For a more detailed explanation see the topic [Writing your first application](../modules/hello_sky.md).
|
||||
|
||||
6. Lastly, add your module in the **default.px4board** file correspondent to your board in **PX4-Autopilot/boards/**.
|
||||
For example:
|
||||
-for the Pixhawk 4, add the following code in **PX4-Autopilot/boards/px4/fmu-v5/default.px4board**:
|
||||
-for the SITL, add the following code in **PX4-Autopilot/boards/px4/sitl/default.px4board**
|
||||
|
||||
```
|
||||
CONFIG_MODULES_KEY_RECEIVER=y
|
||||
```
|
||||
|
||||
Тепер ви готові зібрати всю свою роботу!
|
||||
|
||||
## Збірка
|
||||
|
||||
### Збірка для ROS
|
||||
|
||||
1. In your workspace enter: `catkin build`.
|
||||
|
||||
2. Попередньо ви маєте встановити свій "px4.launch" у (/workspace/src/mavros/mavros/launch).
|
||||
Відредагуйте "px4.launch" як нижче.
|
||||
Якщо ви використовуєте USB для підключення комп'ютера до Pixhawk, ви повинні встановити "fcu_url" як показано нижче.
|
||||
Проте, якщо ви використовуєте CP2102 для підключення комп'ютера до Pixhawk, вам необхідно замінити "ttyACM0" на "ttyUSB0".
|
||||
І якщо ви використовуєте SITL для підключення до свого терміналу, ви повинні замінити "/dev/ttyACM0:57600" на "udp://:14540@127.0.0.1:14557".
|
||||
Зміна "gcs_url" означає підключення Pixhawk через UDP, оскільки послідовний зв'язок не може одночасно приймати MAVROS і ваше з'єднання з оболонкою.
|
||||
|
||||
3. Введіть свою IP-адресу у вигляді "xxx.xx.xxx.xxx"
|
||||
```xml
|
||||
...
|
||||
<arg name="fcu_url" default="/dev/ttyACM0:57600" />
|
||||
<arg name="gcs_url" default="udp://:14550@xxx.xx.xxx.xxx:14557" />
|
||||
...
|
||||
```
|
||||
|
||||
### Збірка для PX4
|
||||
|
||||
1. Очистіть попередньо зібраний каталог PX4-Autopilot. In the root of **PX4-Autopilot** directory:
|
||||
```sh
|
||||
make clean
|
||||
```
|
||||
|
||||
2. Build PX4-Autopilot and upload [in the normal way](../dev_setup/building_px4.md#nuttx-pixhawk-based-boards).
|
||||
|
||||
Наприклад:
|
||||
|
||||
- щоб зібрати для Pixhawk 4/FMUv5, виконайте наступну команду у корені каталогу PX4-Autopilot:
|
||||
|
||||
```sh
|
||||
make px4_fmu-v5_default upload
|
||||
```
|
||||
|
||||
- для SITL потрібно виконати наступну команду в кореневому каталозі PX4-Autopilot (використовуючи jmavsim simulation):
|
||||
|
||||
```sh
|
||||
make px4_sitl jmavsim
|
||||
```
|
||||
|
||||
## Запуск коду
|
||||
|
||||
Далі перевірте, чи надсилається повідомлення MAVROS на PX4.
|
||||
|
||||
### Запуск ROS
|
||||
|
||||
1. У терміналі введіть
|
||||
```sh
|
||||
roslaunch mavros px4.launch
|
||||
```
|
||||
2. В другому терміналі запустить:
|
||||
```sh
|
||||
rostopic pub -r 10 /mavros/keyboard_command/keyboard_sub std_msgs/Char 97
|
||||
```
|
||||
Це означає, що потрібно опублікувати 97 ('a' в ASCII) у темі ROS "/mavros/keyboard_command/keyboard_sub" з типом повідомлення "std_msgs/Char". "-r 10" означає безперервну публікацію з частотою "10 Гц".
|
||||
|
||||
### Запуск PX4
|
||||
|
||||
1. Введіть оболонку Pixhawk через UDP.
|
||||
Замініть xxx.xx.xxx.xxx своїм IP.
|
||||
```sh
|
||||
cd PX4-Autopilot/Tools
|
||||
./mavlink_shell.py xxx.xx.xxx.xxx:14557 --baudrate 57600
|
||||
```
|
||||
|
||||
2. After few seconds, press **Enter** a couple of times.
|
||||
Ви маєте побачити запит в терміналі, як нижче:
|
||||
```sh
|
||||
nsh>
|
||||
nsh>
|
||||
```
|
||||
Введіть "key_receiver", щоб запустити модуль підписника.
|
||||
```
|
||||
nsh> key_receiver
|
||||
```
|
||||
|
||||
Check if it successfully receives `a` from your ROS topic.
|
||||
@@ -0,0 +1,210 @@
|
||||
# ROS (1) with MAVROS Installation Guide
|
||||
|
||||
:::warning
|
||||
The PX4 development team recommend that all users [upgrade to ROS 2](../ros2/index.md).
|
||||
Ця документація відображає "старий підхід".
|
||||
:::
|
||||
|
||||
This documentation explains how to set up communication between the PX4 Autopilot and a ROS 1 enabled companion computer using MAVROS.
|
||||
|
||||
[MAVROS](http://wiki.ros.org/mavros#mavros.2BAC8-Plugins.sys_status) is a ROS 1 package that enables MAVLink extendable communication between computers running ROS 1 for any MAVLink enabled autopilot, ground station, or peripheral.
|
||||
_MAVROS_ is the "official" supported bridge between ROS 1 and the MAVLink protocol.
|
||||
|
||||
First we install PX4 and ROS, and then MAVROS.
|
||||
|
||||
## Install ROS and PX4
|
||||
|
||||
This section explains how to install [ROS 1](../ros/index.md) with PX4.
|
||||
ROS 1 full desktop builds come with Gazebo Classic, so normally you will not install the simulator dependencies yourself!
|
||||
|
||||
:::tip
|
||||
These instructions are a simplified version of the [official installation guide](https://github.com/mavlink/mavros/tree/master/mavros#installation).
|
||||
They cover the _ROS Melodic and Noetic_ releases.
|
||||
:::
|
||||
|
||||
:::: tabs
|
||||
|
||||
:::tab ROS Noetic (Ubuntu 20.04)
|
||||
|
||||
If you're working with [ROS Noetic](http://wiki.ros.org/noetic) on Ubuntu 20.04:
|
||||
|
||||
1. Install PX4 without the simulator toolchain:
|
||||
|
||||
1. [Download PX4 Source Code](../dev_setup/building_px4.md):
|
||||
|
||||
```sh
|
||||
git clone https://github.com/PX4/PX4-Autopilot.git --recursive
|
||||
```
|
||||
|
||||
2. Run the **ubuntu.sh** the `--no-sim-tools` (and optionally `--no-nuttx`):
|
||||
|
||||
```sh
|
||||
bash ./PX4-Autopilot/Tools/setup/ubuntu.sh --no-sim-tools --no-nuttx
|
||||
```
|
||||
|
||||
- При появі підказки по ходу виконання скрипту підтвердить вибір.
|
||||
|
||||
3. Перезавантажте комп'ютер при завершенні.
|
||||
|
||||
2. You _may_ need to install the following additional dependencies:
|
||||
|
||||
```sh
|
||||
sudo apt-get install protobuf-compiler libeigen3-dev libopencv-dev -y
|
||||
```
|
||||
|
||||
3. Follow the [Noetic Installation instructions](http://wiki.ros.org/noetic/Installation/Ubuntu#Installation) (ros-noetic-desktop-full is recommended).
|
||||
|
||||
:::
|
||||
|
||||
:::tab ROS Melodic (Ubuntu 18.04)
|
||||
|
||||
If you're working with ROS "Melodic on Ubuntu 18.04:
|
||||
|
||||
1. Download the [ubuntu_sim_ros_melodic.sh](https://raw.githubusercontent.com/PX4/Devguide/master/build_scripts/ubuntu_sim_ros_melodic.sh) script in a bash shell:
|
||||
|
||||
```sh
|
||||
wget https://raw.githubusercontent.com/PX4/Devguide/master/build_scripts/ubuntu_sim_ros_melodic.sh
|
||||
```
|
||||
|
||||
2. Run the script:
|
||||
|
||||
```sh
|
||||
bash ubuntu_sim_ros_melodic.sh
|
||||
```
|
||||
|
||||
You may need to acknowledge some prompts as the script progresses.
|
||||
|
||||
::: tip
|
||||
You don't need to install MAVROS (as shown below), as this is included by the script
|
||||
|
||||
Also note:
|
||||
|
||||
- ROS Melodic is installed with Gazebo (Classic) 9 by default.
|
||||
- Your catkin (ROS build system) workspace is created at **~/catkin_ws/**.
|
||||
- The script uses instructions from the ROS Wiki "Melodic" [Ubuntu page](http://wiki.ros.org/melodic/Installation/Ubuntu).
|
||||
|
||||
:::
|
||||
|
||||
::::
|
||||
|
||||
## Install MAVROS
|
||||
|
||||
Then MAVROS can be installed either from source or binary.
|
||||
Ми рекомендуємо розробникам використовувати початкове встановлення.
|
||||
|
||||
#### Бінарне встановлення (Debian / Ubuntu)
|
||||
|
||||
The ROS repository has binary packages for Ubuntu x86, amd64 (x86_64) and armhf (ARMv7).
|
||||
Kinetic також підтримує Debian Jessie amd64 і arm64 (ARMv8).
|
||||
|
||||
Use `apt-get` for installation, where `${ROS_DISTRO}` below should resolve to `kinetic` or `noetic`, depending on your version of ROS:
|
||||
|
||||
```sh
|
||||
sudo apt-get install ros-${ROS_DISTRO}-mavros ros-${ROS_DISTRO}-mavros-extras ros-${ROS_DISTRO}-mavros-msgs
|
||||
```
|
||||
|
||||
Then install [GeographicLib](https://geographiclib.sourceforge.io/) datasets by running the `install_geographiclib_datasets.sh` script:
|
||||
|
||||
```sh
|
||||
wget https://raw.githubusercontent.com/mavlink/mavros/master/mavros/scripts/install_geographiclib_datasets.sh
|
||||
sudo bash ./install_geographiclib_datasets.sh
|
||||
```
|
||||
|
||||
#### Встановлення початкового коду
|
||||
|
||||
This installation assumes you have a catkin workspace located at `~/catkin_ws` If you don't create one with:
|
||||
|
||||
```sh
|
||||
mkdir -p ~/catkin_ws/src
|
||||
cd ~/catkin_ws
|
||||
catkin init
|
||||
wstool init src
|
||||
```
|
||||
|
||||
You will be using the ROS Python tools: _wstool_ (for retrieving sources), _rosinstall_, and _catkin_tools_ (building) for this installation. Хоча вони могли бути встановлені під час інсталяції ROS, ви також можете встановити їх разом з ним:
|
||||
|
||||
```sh
|
||||
sudo apt-get install python-catkin-tools python-rosinstall-generator -y
|
||||
```
|
||||
|
||||
:::tip
|
||||
While the package can be built using **catkin_make** the preferred method is using **catkin_tools** as it is a more versatile and "friendly" build tool.
|
||||
:::
|
||||
|
||||
Якщо це ваш перший раз за допомогою wstool вам потрібно буде ініціалізувати свій вихідний простір з:
|
||||
|
||||
```sh
|
||||
$ wstool init ~/catkin_ws/src
|
||||
```
|
||||
|
||||
Тепер ви готові зробити збірку:
|
||||
|
||||
1. Встановіть MAVLink:
|
||||
|
||||
```sh
|
||||
# We use the Kinetic reference for all ROS distros as it's not distro-specific and up to date
|
||||
rosinstall_generator --rosdistro kinetic mavlink | tee /tmp/mavros.rosinstall
|
||||
```
|
||||
|
||||
2. Встановити MAVROS з джерела, використовуючи як випущену, так і останню версію:
|
||||
|
||||
- Випущений реліз/стабільний
|
||||
|
||||
```sh
|
||||
rosinstall_generator --upstream mavros | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
|
||||
- Найновіше джерело
|
||||
|
||||
```sh
|
||||
rosinstall_generator --upstream-development mavros | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
|
||||
```sh
|
||||
# For fetching all the dependencies into your catkin_ws,
|
||||
# just add '--deps' to the above scripts, E.g.:
|
||||
# rosinstall_generator --upstream mavros --deps | tee -a /tmp/mavros.rosinstall
|
||||
```
|
||||
|
||||
3. Create workspace & deps
|
||||
|
||||
```sh
|
||||
wstool merge -t src /tmp/mavros.rosinstall
|
||||
wstool update -t src -j4
|
||||
rosdep install --from-paths src --ignore-src -y
|
||||
```
|
||||
|
||||
4. Install [GeographicLib](https://geographiclib.sourceforge.io/) datasets:
|
||||
|
||||
```sh
|
||||
./src/mavros/mavros/scripts/install_geographiclib_datasets.sh
|
||||
```
|
||||
|
||||
5. Джерело збірки
|
||||
|
||||
```sh
|
||||
catkin build
|
||||
```
|
||||
|
||||
6. Переконайтеся, що ви використовуєте setup.bash або setup.zsh з робочого простору.
|
||||
|
||||
```sh
|
||||
#Needed or rosrun can't find nodes from this workspace.
|
||||
source devel/setup.bash
|
||||
```
|
||||
|
||||
In the case of error, there are addition installation and troubleshooting notes in the [mavros repo](https://github.com/mavlink/mavros/tree/master/mavros#installation).
|
||||
|
||||
## MAVROS Приклади
|
||||
|
||||
The [MAVROS Offboard Example (C++)](../ros/mavros_offboard_cpp.md), will show you the basics of MAVROS, from reading telemetry, checking the drone state, changing flight modes and controlling the drone.
|
||||
|
||||
:::info
|
||||
If you have an example app using the PX4 Autopilot and MAVROS, we can help you get it on our docs.
|
||||
:::
|
||||
|
||||
## Дивіться також
|
||||
|
||||
- [mavros ROS Package Summary](http://wiki.ros.org/mavros#mavros.2BAC8-Plugins.sys_status)
|
||||
- [mavros source](https://github.com/mavlink/mavros/)
|
||||
- [ROS Melodic installation instructions](http://wiki.ros.org/melodic/Installation)
|
||||
@@ -0,0 +1,236 @@
|
||||
# MAVROS _Offboard_ control example (C++)
|
||||
|
||||
This tutorial shows the basics of _Offboard_ control with MAVROS, using an Iris quadcopter simulated in Gazebo Classic/SITL.
|
||||
У кінці посібника ви повинні побачити таку ж поведінку, як і в нижченаведеному відео, повільний зліт на висоту 2 метри.
|
||||
|
||||
:::warning
|
||||
_Offboard_ control is dangerous.
|
||||
Якщо ви керуєте реальним транспортним засобом, то обов'язково майте можливість отримати назад ручне керування на випадок, якщо щось піде не так.
|
||||
:::
|
||||
|
||||
:::tip
|
||||
This example uses C++.
|
||||
A very similar example for Python can be found in [ROS/MAVROS Offboard Example (Python)](../ros/mavros_offboard_python.md) (also see the examples in [integrationtests/python_src/px4_it/mavros](https://github.com/PX4/PX4-Autopilot/tree/main/integrationtests/python_src/px4_it/mavros)).
|
||||
:::
|
||||
|
||||
<video width="100%" autoplay="true" controls="true">
|
||||
<source src="../../assets/simulation/gazebo_classic/gazebo_offboard.webm" type="video/webm">
|
||||
</video>
|
||||
|
||||
## Код
|
||||
|
||||
Create the `offb_node.cpp` file in your ROS package (by also adding it to your `CMakeList.txt` so it is compiled), and paste the following inside it:
|
||||
|
||||
```cpp
|
||||
/**
|
||||
* @file offb_node.cpp
|
||||
* @brief Offboard control example node, written with MAVROS version 0.19.x, PX4 Pro Flight
|
||||
* Stack and tested in Gazebo Classic SITL
|
||||
*/
|
||||
|
||||
#include <ros/ros.h>
|
||||
#include <geometry_msgs/PoseStamped.h>
|
||||
#include <mavros_msgs/CommandBool.h>
|
||||
#include <mavros_msgs/SetMode.h>
|
||||
#include <mavros_msgs/State.h>
|
||||
|
||||
mavros_msgs::State current_state;
|
||||
void state_cb(const mavros_msgs::State::ConstPtr& msg){
|
||||
current_state = *msg;
|
||||
}
|
||||
|
||||
int main(int argc, char **argv)
|
||||
{
|
||||
ros::init(argc, argv, "offb_node");
|
||||
ros::NodeHandle nh;
|
||||
|
||||
ros::Subscriber state_sub = nh.subscribe<mavros_msgs::State>
|
||||
("mavros/state", 10, state_cb);
|
||||
ros::Publisher local_pos_pub = nh.advertise<geometry_msgs::PoseStamped>
|
||||
("mavros/setpoint_position/local", 10);
|
||||
ros::ServiceClient arming_client = nh.serviceClient<mavros_msgs::CommandBool>
|
||||
("mavros/cmd/arming");
|
||||
ros::ServiceClient set_mode_client = nh.serviceClient<mavros_msgs::SetMode>
|
||||
("mavros/set_mode");
|
||||
|
||||
//the setpoint publishing rate MUST be faster than 2Hz
|
||||
ros::Rate rate(20.0);
|
||||
|
||||
// wait for FCU connection
|
||||
while(ros::ok() && !current_state.connected){
|
||||
ros::spinOnce();
|
||||
rate.sleep();
|
||||
}
|
||||
|
||||
geometry_msgs::PoseStamped pose;
|
||||
pose.pose.position.x = 0;
|
||||
pose.pose.position.y = 0;
|
||||
pose.pose.position.z = 2;
|
||||
|
||||
//send a few setpoints before starting
|
||||
for(int i = 100; ros::ok() && i > 0; --i){
|
||||
local_pos_pub.publish(pose);
|
||||
ros::spinOnce();
|
||||
rate.sleep();
|
||||
}
|
||||
|
||||
mavros_msgs::SetMode offb_set_mode;
|
||||
offb_set_mode.request.custom_mode = "OFFBOARD";
|
||||
|
||||
mavros_msgs::CommandBool arm_cmd;
|
||||
arm_cmd.request.value = true;
|
||||
|
||||
ros::Time last_request = ros::Time::now();
|
||||
|
||||
while(ros::ok()){
|
||||
if( current_state.mode != "OFFBOARD" &&
|
||||
(ros::Time::now() - last_request > ros::Duration(5.0))){
|
||||
if( set_mode_client.call(offb_set_mode) &&
|
||||
offb_set_mode.response.mode_sent){
|
||||
ROS_INFO("Offboard enabled");
|
||||
}
|
||||
last_request = ros::Time::now();
|
||||
} else {
|
||||
if( !current_state.armed &&
|
||||
(ros::Time::now() - last_request > ros::Duration(5.0))){
|
||||
if( arming_client.call(arm_cmd) &&
|
||||
arm_cmd.response.success){
|
||||
ROS_INFO("Vehicle armed");
|
||||
}
|
||||
last_request = ros::Time::now();
|
||||
}
|
||||
}
|
||||
|
||||
local_pos_pub.publish(pose);
|
||||
|
||||
ros::spinOnce();
|
||||
rate.sleep();
|
||||
}
|
||||
|
||||
return 0;
|
||||
}
|
||||
|
||||
```
|
||||
|
||||
## Пояснення коду
|
||||
|
||||
```cpp
|
||||
#include <ros/ros.h>
|
||||
#include <geometry_msgs/PoseStamped.h>
|
||||
#include <mavros_msgs/CommandBool.h>
|
||||
#include <mavros_msgs/SetMode.h>
|
||||
#include <mavros_msgs/State.h>
|
||||
```
|
||||
|
||||
The `mavros_msgs` package contains all of the custom messages required to operate services and topics provided by the MAVROS package.
|
||||
All services and topics as well as their corresponding message types are documented in the [mavros wiki](http://wiki.ros.org/mavros).
|
||||
|
||||
```cpp
|
||||
mavros_msgs::State current_state;
|
||||
void state_cb(const mavros_msgs::State::ConstPtr& msg){
|
||||
current_state = *msg;
|
||||
}
|
||||
```
|
||||
|
||||
Ми створюємо простий виклик, який буде зберігати поточний стан автопілота.
|
||||
This will allow us to check connection, arming and _Offboard_ flags.
|
||||
|
||||
```cpp
|
||||
ros::Subscriber state_sub = nh.subscribe<mavros_msgs::State>("mavros/state", 10, state_cb);
|
||||
ros::Publisher local_pos_pub = nh.advertise<geometry_msgs::PoseStamped>("mavros/setpoint_position/local", 10);
|
||||
ros::ServiceClient arming_client = nh.serviceClient<mavros_msgs::CommandBool>("mavros/cmd/arming");
|
||||
ros::ServiceClient set_mode_client = nh.serviceClient<mavros_msgs::SetMode>("mavros/set_mode");
|
||||
```
|
||||
|
||||
Ми створюємо екземпляр видавця для публікації командної локальної позиції та відповідних клієнтів для запиту на arming та зміни режиму.
|
||||
Зверніть увагу, що для вашої власної системи, префікс "mavros" може відрізнятися, так як це буде залежати від імені, даного вузлу в файлі запуску.
|
||||
|
||||
```cpp
|
||||
//the setpoint publishing rate MUST be faster than 2Hz
|
||||
ros::Rate rate(20.0);
|
||||
```
|
||||
|
||||
PX4 has a timeout of 500ms between two _Offboard_ commands.
|
||||
If this timeout is exceeded, the commander will fall back to the last mode the vehicle was in before entering _Offboard_ mode.
|
||||
This is why the publishing rate **must** be faster than 2 Hz to also account for possible latencies.
|
||||
This is also the same reason why it is recommended to enter _Offboard_ mode from _Position_ mode, this way if the vehicle drops out of _Offboard_ mode it will stop in its tracks and hover.
|
||||
|
||||
```cpp
|
||||
// wait for FCU connection
|
||||
while(ros::ok() && !current_state.connected){
|
||||
ros::spinOnce();
|
||||
rate.sleep();
|
||||
}
|
||||
```
|
||||
|
||||
Перш ніж щось публікувати, ми чекаємо встановлення зв'язку між MAVROS і автопілотом.
|
||||
Цей цикл має закінчитись, щойно буде отримано повідомлення про hearbeat.
|
||||
|
||||
```cpp
|
||||
geometry_msgs::PoseStamped pose;
|
||||
pose.pose.position.x = 0;
|
||||
pose.pose.position.y = 0;
|
||||
pose.pose.position.z = 2;
|
||||
```
|
||||
|
||||
Попри те, що PX4 Pro Flight Stack працює в координатній площині NED, MAVROS переводить ці координати до ENU стандарту та навпаки.
|
||||
This is why we set `z` to positive 2.
|
||||
|
||||
```cpp
|
||||
//send a few setpoints before starting
|
||||
for(int i = 100; ros::ok() && i > 0; --i){
|
||||
local_pos_pub.publish(pose);
|
||||
ros::spinOnce();
|
||||
rate.sleep();
|
||||
}
|
||||
```
|
||||
|
||||
Before entering _Offboard_ mode, you must have already started streaming setpoints.
|
||||
В іншому випадку перемикач режиму буде відхилено. Here, `100` was chosen as an arbitrary amount.
|
||||
|
||||
```cpp
|
||||
mavros_msgs::SetMode offb_set_mode;
|
||||
offb_set_mode.request.custom_mode = "OFFBOARD";
|
||||
```
|
||||
|
||||
We set the custom mode to `OFFBOARD`.
|
||||
A list of [supported modes](http://wiki.ros.org/mavros/CustomModes#PX4_native_flight_stack) is available for reference.
|
||||
|
||||
```cpp
|
||||
mavros_msgs::CommandBool arm_cmd;
|
||||
arm_cmd.request.value = true;
|
||||
|
||||
ros::Time last_request = ros::Time::now();
|
||||
|
||||
while(ros::ok()){
|
||||
if( current_state.mode != "OFFBOARD" &&
|
||||
(ros::Time::now() - last_request > ros::Duration(5.0))){
|
||||
if( set_mode_client.call(offb_set_mode) && offb_set_mode.response.mode_sent) {
|
||||
ROS_INFO("Offboard enabled");
|
||||
}
|
||||
last_request = ros::Time::now();
|
||||
} else {
|
||||
if( !current_state.armed && (ros::Time::now() - last_request > ros::Duration(5.0))) {
|
||||
if( arming_client.call(arm_cmd) && arm_cmd.response.success) {
|
||||
ROS_INFO("Vehicle armed");
|
||||
}
|
||||
last_request = ros::Time::now();
|
||||
}
|
||||
}
|
||||
|
||||
local_pos_pub.publish(pose);
|
||||
|
||||
ros::spinOnce();
|
||||
rate.sleep();
|
||||
}
|
||||
```
|
||||
|
||||
Решта коду досить зрозуміла.
|
||||
We attempt to switch to _Offboard_ mode, after which we arm the quad to allow it to fly.
|
||||
Ми визначаємо паузу виклику сервісів у 5 секунд, щоб не перевантажити автопілот запитами.
|
||||
В тому ж циклі ми продовжуємо надсилати запитану позицію за частотою, яка раніше визначена.
|
||||
|
||||
:::tip
|
||||
This code has been simplified to the bare minimum for illustration purposes.
|
||||
У великих системах часто корисно створити новий потік, який буде відповідати за періодичну публікацію заданих значень.
|
||||
:::
|
||||
@@ -0,0 +1,364 @@
|
||||
# MAVROS _Offboard_ control example (Python)
|
||||
|
||||
This tutorial shows the basics of _OFFBOARD_ control with MAVROS Python, using an Iris quadcopter simulated in [Gazebo Classic](../sim_gazebo_classic/index.md).
|
||||
Він надає покрокові інструкції, що демонструють як почати розробку програм для керування засобом та виконання коду в симуляції.
|
||||
|
||||
У кінці посібника ви повинні побачити таку ж поведінку, як і в нижченаведеному відео, повільний зліт на висоту 2 метри.
|
||||
|
||||
:::warning
|
||||
_OFFBOARD_ control is dangerous.
|
||||
Якщо ви керуєте реальним транспортним засобом, то обов'язково майте можливість отримати назад ручне керування на випадок, якщо щось піде не так.
|
||||
:::
|
||||
|
||||
:::tip
|
||||
This example uses Python.
|
||||
Other examples in Python can be found here: [integrationtests/python_src/px4_it/mavros](https://github.com/PX4/PX4-Autopilot/tree/main/integrationtests/python_src/px4_it/mavros).
|
||||
:::
|
||||
|
||||
<a id="offb_video"></a>
|
||||
|
||||
<video width="100%" autoplay="true" controls="true">
|
||||
<source src="../../assets/simulation/gazebo_classic/gazebo_offboard.webm" type="video/webm">
|
||||
</video>
|
||||
|
||||
## Створення пакету ROS
|
||||
|
||||
1. Open the terminal and go to `~/catkin_ws/src` directory
|
||||
|
||||
```sh
|
||||
roscd # Should cd into ~/catkin_ws/devel
|
||||
cd ..
|
||||
cd src
|
||||
```
|
||||
|
||||
2. In the `~/catkin_ws/src` directory create a new package named `offboard_py` (in this case) with the `rospy` dependency:
|
||||
|
||||
```sh
|
||||
catkin_create_pkg offboard_py rospy
|
||||
```
|
||||
|
||||
3. Build the new package in the `~/catkin_ws/` directory:
|
||||
|
||||
```sh
|
||||
cd .. # Assuming previous directory to be ~/catkin_ws/src
|
||||
catkin build
|
||||
source devel/setup.bash
|
||||
```
|
||||
|
||||
4. Тепер ви можете мати можливість перейти до пакета, використовуючи:
|
||||
|
||||
```sh
|
||||
```
|
||||
|
||||
5. To store your Python files, create a new folder called `/scripts` on the package:
|
||||
|
||||
```sh
|
||||
mkdir scripts
|
||||
cd scripts
|
||||
```
|
||||
|
||||
## Код
|
||||
|
||||
Після створення пакету ROS та директорії скриптів, ви готові до запуску вашого Python скрипту.
|
||||
Inside the scripts folder create the `offb_node.py` file and give it executable permissions:
|
||||
|
||||
```sh
|
||||
touch offb_node.py
|
||||
chmod +x offb_node.py
|
||||
```
|
||||
|
||||
After that, open `offb_node.py` file and paste the following code:
|
||||
|
||||
```py
|
||||
"""
|
||||
* File: offb_node.py
|
||||
* Stack and tested in Gazebo Classic 9 SITL
|
||||
"""
|
||||
|
||||
#! /usr/bin/env python
|
||||
|
||||
import rospy
|
||||
from geometry_msgs.msg import PoseStamped
|
||||
from mavros_msgs.msg import State
|
||||
from mavros_msgs.srv import CommandBool, CommandBoolRequest, SetMode, SetModeRequest
|
||||
|
||||
current_state = State()
|
||||
|
||||
def state_cb(msg):
|
||||
global current_state
|
||||
current_state = msg
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
rospy.init_node("offb_node_py")
|
||||
|
||||
state_sub = rospy.Subscriber("mavros/state", State, callback = state_cb)
|
||||
|
||||
local_pos_pub = rospy.Publisher("mavros/setpoint_position/local", PoseStamped, queue_size=10)
|
||||
|
||||
rospy.wait_for_service("/mavros/cmd/arming")
|
||||
arming_client = rospy.ServiceProxy("mavros/cmd/arming", CommandBool)
|
||||
|
||||
rospy.wait_for_service("/mavros/set_mode")
|
||||
set_mode_client = rospy.ServiceProxy("mavros/set_mode", SetMode)
|
||||
|
||||
|
||||
# Setpoint publishing MUST be faster than 2Hz
|
||||
rate = rospy.Rate(20)
|
||||
|
||||
# Wait for Flight Controller connection
|
||||
while(not rospy.is_shutdown() and not current_state.connected):
|
||||
rate.sleep()
|
||||
|
||||
pose = PoseStamped()
|
||||
|
||||
pose.pose.position.x = 0
|
||||
pose.pose.position.y = 0
|
||||
pose.pose.position.z = 2
|
||||
|
||||
# Send a few setpoints before starting
|
||||
for i in range(100):
|
||||
if(rospy.is_shutdown()):
|
||||
break
|
||||
|
||||
local_pos_pub.publish(pose)
|
||||
rate.sleep()
|
||||
|
||||
offb_set_mode = SetModeRequest()
|
||||
offb_set_mode.custom_mode = 'OFFBOARD'
|
||||
|
||||
arm_cmd = CommandBoolRequest()
|
||||
arm_cmd.value = True
|
||||
|
||||
last_req = rospy.Time.now()
|
||||
|
||||
while(not rospy.is_shutdown()):
|
||||
if(current_state.mode != "OFFBOARD" and (rospy.Time.now() - last_req) > rospy.Duration(5.0)):
|
||||
if(set_mode_client.call(offb_set_mode).mode_sent == True):
|
||||
rospy.loginfo("OFFBOARD enabled")
|
||||
|
||||
last_req = rospy.Time.now()
|
||||
else:
|
||||
if(not current_state.armed and (rospy.Time.now() - last_req) > rospy.Duration(5.0)):
|
||||
if(arming_client.call(arm_cmd).success == True):
|
||||
rospy.loginfo("Vehicle armed")
|
||||
|
||||
last_req = rospy.Time.now()
|
||||
|
||||
local_pos_pub.publish(pose)
|
||||
|
||||
rate.sleep()
|
||||
|
||||
```
|
||||
|
||||
## Пояснення коду
|
||||
|
||||
The `mavros_msgs` package contains all of the custom messages required to operate services and topics provided by the MAVROS package.
|
||||
All services and topics as well as their corresponding message types are documented in the [mavros wiki](http://wiki.ros.org/mavros).
|
||||
|
||||
```py
|
||||
import rospy
|
||||
from geometry_msgs.msg import PoseStamped
|
||||
from mavros_msgs.msg import State
|
||||
from mavros_msgs.srv import CommandBool, CommandBoolRequest, SetMode, SetModeRequest
|
||||
```
|
||||
|
||||
Ми створюємо простий виклик, який буде зберігати поточний стан автопілота.
|
||||
This will allow us to check connection, arming and _OFFBOARD_ flags.:
|
||||
|
||||
```py
|
||||
current_state = State()
|
||||
|
||||
def state_cb(msg):
|
||||
global current_state
|
||||
current_state = msg
|
||||
```
|
||||
|
||||
Ми створюємо екземпляр видавця для публікації командної локальної позиції та відповідних клієнтів для запиту на arming та зміни режиму.
|
||||
Зверніть увагу, що для вашої власної системи, префікс "mavros" може відрізнятися, так як це буде залежати від імені, даного вузлу в файлі запуску.
|
||||
|
||||
```py
|
||||
state_sub = rospy.Subscriber("mavros/state", State, callback = state_cb)
|
||||
|
||||
local_pos_pub = rospy.Publisher("mavros/setpoint_position/local", PoseStamped, queue_size=10)
|
||||
|
||||
rospy.wait_for_service("/mavros/cmd/arming")
|
||||
arming_client = rospy.ServiceProxy("mavros/cmd/arming", CommandBool)
|
||||
|
||||
rospy.wait_for_service("/mavros/set_mode")
|
||||
set_mode_client = rospy.ServiceProxy("mavros/set_mode", SetMode)
|
||||
```
|
||||
|
||||
PX4 has a timeout of 500ms between two _OFFBOARD_ commands.
|
||||
If this timeout is exceeded, the commander will fall back to the last mode the vehicle was in before entering _OFFBOARD_ mode.
|
||||
This is why the publishing rate **must** be faster than 2 Hz to also account for possible latencies.
|
||||
This is also the same reason why it is **recommended to enter _OFFBOARD_ mode from _Position_ mode**, this way if the vehicle drops out of _OFFBOARD_ mode it will stop in its tracks and hover.
|
||||
|
||||
Тут ми відповідно встановлюємо швидкість публікації:
|
||||
|
||||
```py
|
||||
# Setpoint publishing MUST be faster than 2Hz
|
||||
rate = rospy.Rate(20)
|
||||
```
|
||||
|
||||
Перш ніж щось публікувати, ми чекаємо встановлення зв'язку між MAVROS і автопілотом.
|
||||
Цей цикл має закінчитись, щойно буде отримано повідомлення про hearbeat.
|
||||
|
||||
```py
|
||||
# Wait for Flight Controller connection
|
||||
while(not rospy.is_shutdown() and not current_state.connected):
|
||||
rate.sleep()
|
||||
```
|
||||
|
||||
Попри те, що PX4 працює в координатній площині NED, MAVROS переводить ці координати до ENU стандарту та навпаки.
|
||||
This is why we set `z` to positive 2:
|
||||
|
||||
```py
|
||||
pose = PoseStamped()
|
||||
|
||||
pose.pose.position.x = 0
|
||||
pose.pose.position.y = 0
|
||||
pose.pose.position.z = 2
|
||||
```
|
||||
|
||||
Before entering _OFFBOARD_ mode, you must have already started streaming setpoints.
|
||||
В іншому випадку перемикач режиму буде відхилено.
|
||||
Below, `100` was chosen as an arbitrary amount.
|
||||
|
||||
```py
|
||||
# Send a few setpoints before starting
|
||||
for i in range(100):
|
||||
if(rospy.is_shutdown()):
|
||||
break
|
||||
|
||||
local_pos_pub.publish(pose)
|
||||
rate.sleep()
|
||||
```
|
||||
|
||||
We prepare the message request used to set the custom mode to `OFFBOARD`.
|
||||
A list of [supported modes](http://wiki.ros.org/mavros/CustomModes#PX4_native_flight_stack) is available for reference.
|
||||
|
||||
```py
|
||||
offb_set_mode = SetModeRequest()
|
||||
offb_set_mode.custom_mode = 'OFFBOARD'
|
||||
```
|
||||
|
||||
Решта коду є значною мірою поясненням.
|
||||
We attempt to switch to _Offboard_ mode, after which we arm the quad to allow it to fly.
|
||||
Ми визначаємо паузу виклику сервісів у 5 секунд, щоб не перевантажити автопілот запитами.
|
||||
В тому ж циклі ми продовжуємо надсилати запитану позицію за частотою, яка раніше визначена.
|
||||
|
||||
```py
|
||||
arm_cmd = CommandBoolRequest()
|
||||
arm_cmd.value = True
|
||||
|
||||
last_req = rospy.Time.now()
|
||||
|
||||
while(not rospy.is_shutdown()):
|
||||
if(current_state.mode != "OFFBOARD" and (rospy.Time.now() - last_req) > rospy.Duration(5.0)):
|
||||
if(set_mode_client.call(offb_set_mode).mode_sent == True):
|
||||
rospy.loginfo("OFFBOARD enabled")
|
||||
|
||||
last_req = rospy.Time.now()
|
||||
else:
|
||||
if(not current_state.armed and (rospy.Time.now() - last_req) > rospy.Duration(5.0)):
|
||||
if(arming_client.call(arm_cmd).success == True):
|
||||
rospy.loginfo("Vehicle armed")
|
||||
|
||||
last_req = rospy.Time.now()
|
||||
|
||||
local_pos_pub.publish(pose)
|
||||
|
||||
rate.sleep()
|
||||
```
|
||||
|
||||
:::tip
|
||||
This code has been simplified to the bare minimum for illustration purposes.
|
||||
У великих системах часто корисно створити новий потік, який буде відповідати за періодичну публікацію заданих значень.
|
||||
:::
|
||||
|
||||
## Створення ROS launch файлу
|
||||
|
||||
In your `offboard_py` package, create another folder inside the `~/catkin_ws/src/offboard_py/src` directory named `launch`.
|
||||
Саме тут будуть зберігатися файли запуску пакету.
|
||||
After that, create your first launch file, in this case we will call it `start_offb.launch`.
|
||||
|
||||
```sh
|
||||
roscd offboard_py
|
||||
mkdir launch
|
||||
cd launch
|
||||
touch start_offb.launch
|
||||
```
|
||||
|
||||
For the `start_offb.launch` copy the following code:
|
||||
|
||||
```xml
|
||||
<?xml version="1.0"?>
|
||||
<launch>
|
||||
<!-- Include the MAVROS node with SITL and Gazebo -->
|
||||
<include file="$(find px4)/launch/mavros_posix_sitl.launch">
|
||||
</include>
|
||||
|
||||
<!-- Our node to control the drone -->
|
||||
<node pkg="offboard_py" type="offb_node.py" name="offb_node_py" required="true" output="screen" />
|
||||
</launch>
|
||||
```
|
||||
|
||||
As you can see, the `mavros_posix_sitl.launch` file is included.
|
||||
This file is responsible for launching MAVROS, the PX4 SITL, the Gazebo Classic Environment and for spawning a vehicle in a given world (for further information see the file [here](https://github.com/PX4/PX4-Autopilot/blob/main/launch/mavros_posix_sitl.launch)).
|
||||
|
||||
:::tip
|
||||
The `mavros_posix_sitl.launch` file takes several arguments that can be set according to your preferences such as the vehicle to spawn or the Gazebo Classic world (refer to [here](https://github.com/PX4/PX4-Autopilot/blob/main/launch/mavros_posix_sitl.launch)) for a complete list).
|
||||
|
||||
You can override the default value of these arguments defined in `mavros_posix_sitl.launch` by declaring them inside the _include_ tags.
|
||||
As an example, if you wanted to spawn the vehicle in the `warehouse.world`, you would write the following:
|
||||
|
||||
```xml
|
||||
<!-- Include the MAVROS node with SITL and Gazebo -->
|
||||
<include file="$(find px4)/launch/mavros_posix_sitl.launch">
|
||||
<arg name="world" default="$(find mavlink_sitl_gazebo)/worlds/warehouse.world"/>
|
||||
</include>
|
||||
```
|
||||
|
||||
:::
|
||||
|
||||
## Запуск скрипту
|
||||
|
||||
Якщо все зроблено правильно, ви повинні тепер мати можливість запустити і протестувати свій скрипт.
|
||||
|
||||
В терміналі запустить:
|
||||
|
||||
```sh
|
||||
roslaunch offboard_py start_offb.launch
|
||||
```
|
||||
|
||||
Тепер ви повинні побачити ініціацію прошивки PX4 і виконання застосунку в Gazebo Classic.
|
||||
After the _OFFBOARD_ mode is set and the vehicle is armed, the behavior shown in the [video](#offb_video) should be observed.
|
||||
|
||||
:::warning
|
||||
It is possible that when running the script an error appears saying:
|
||||
|
||||
> Resource not found: px4
|
||||
> ROS path [0] = ...
|
||||
> ...
|
||||
|
||||
Це означає, що PX4 SITL не включено в path.
|
||||
To solve this add these lines at the end of the `.bashrc` file:
|
||||
|
||||
```sh
|
||||
source ~/PX4-Autopilot/Tools/simulation/gazebo/setup_gazebo.bash ~/PX4-Autopilot ~/PX4-Autopilot/build/px4_sitl_default
|
||||
export ROS_PACKAGE_PATH=$ROS_PACKAGE_PATH:~/PX4-Autopilot
|
||||
export ROS_PACKAGE_PATH=$ROS_PACKAGE_PATH:~/PX4-Autopilot/Tools/simulation/gazebo-classic/sitl_gazebo-classic
|
||||
export GAZEBO_PLUGIN_PATH=$GAZEBO_PLUGIN_PATH:/usr/lib/x86_64-linux-gnu/gazebo-9/plugins
|
||||
```
|
||||
|
||||
Тепер у терміналі, перейдіть до домашнього каталогу і виконайте наступну команду, щоб застосувати зміни вище до поточного терміналу:
|
||||
|
||||
```sh
|
||||
source .bashrc
|
||||
```
|
||||
|
||||
Після цього кроку, кожного разу, коли ви відкриваєте нове вікно терміналу, вас не повинна турбувати ця помилка.
|
||||
If it appears again, a simple `source .bashrc` should fix it.
|
||||
This solution was obtained from this [issue](https://github.com/mzahana/px4_fast_planner/issues/4) thread, where you can get more information about the problem.
|
||||
:::
|
||||
@@ -0,0 +1,88 @@
|
||||
# Offboard Control
|
||||
|
||||
:::warning
|
||||
[Offboard control](../flight_modes/offboard.md) is dangerous.
|
||||
Це відповідальність розробника переконатися в належній підготовці, тестуванні та заходах безпеки перед польотом.
|
||||
:::
|
||||
|
||||
Ідея зовнішнього контролю полягає в можливості керування стеком керування PX4 за допомогою програмного забезпечення, яке виконується поза автопілотом.
|
||||
This is done through the MAVLink protocol, specifically the [SET_POSITION_TARGET_LOCAL_NED](https://mavlink.io/en/messages/common.html#SET_POSITION_TARGET_LOCAL_NED) and the [SET_ATTITUDE_TARGET](https://mavlink.io/en/messages/common.html#SET_ATTITUDE_TARGET) messages.
|
||||
|
||||
## Налаштування прошивки з зовнішнім контролем
|
||||
|
||||
Є дві речі, які ви маєте налаштувати на стороні прошивки перед початком розробки.
|
||||
|
||||
### Enable RC Override
|
||||
|
||||
In _QGroundControl_ you can set the [COM_RC_OVERRIDE](../advanced_config/parameter_reference.md#COM_RC_OVERRIDE) parameter to automatically switch from offboard mode (or any mode) to Position mode if the RC sticks are moved.
|
||||
This is the best way to ensure that an operator can easily take control of the vehicle and switch to the safest flight mode.
|
||||
|
||||
### Зв'язування RC перемикача з активацією режиму offboard.
|
||||
|
||||
In _QGroundControl_ you can set the [RC_MAP_OFFB_SW](../advanced_config/parameter_reference.md#RC_MAP_OFFB_SW) parameter to the RC channel that will be used to activate offboard mode.
|
||||
This can be used to switch between offboard mode and the mode set by the mode switch ([RC_MAP_MODE_SW](../advanced_config/parameter_reference.md#RC_MAP_MODE_SW)).
|
||||
You can also switch into offboard mode using a GCS/MAVLink so this is not "mandatory".
|
||||
|
||||
Note also that this mechanism is not as "safe" as using [RC Override](#enable-rc-override) to switch out of offboard mode, because the mode you switch to is unpredictable.
|
||||
|
||||
### Увімкніть інтерфейс комп'ютера-компаньйона
|
||||
|
||||
Enable MAVLink on the serial port that you connect to the companion computer (see [Companion Computers](../companion_computer/index.md)).
|
||||
|
||||
## Налаштування обладнання
|
||||
|
||||
Зазвичай, є три способи створення offboard з'єднання.
|
||||
|
||||
### Послідовні радіомодулі
|
||||
|
||||
1. Один підключений до UART порту автопілота
|
||||
2. Один підключений до наземної станції
|
||||
|
||||
Приклад радіомодулів включає:
|
||||
|
||||
- [Lairdtech RM024](http://www.lairdtech.com/products/rm024)
|
||||
- [Digi International XBee Pro](http://www.digi.com/products/xbee-rf-solutions/modules)
|
||||
|
||||
[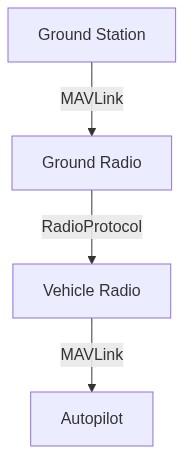](https://mermaid-js.github.io/mermaid-live-editor/#/edit/eyJjb2RlIjoiZ3JhcGggVEQ7XG4gIGduZFtHcm91bmQgU3RhdGlvbl0gLS1NQVZMaW5rLS0-IHJhZDFbR3JvdW5kIFJhZGlvXTtcbiAgcmFkMSAtLVJhZGlvUHJvdG9jb2wtLT4gcmFkMltWZWhpY2xlIFJhZGlvXTtcbiAgcmFkMiAtLU1BVkxpbmstLT4gYVtBdXRvcGlsb3RdOyIsIm1lcm1haWQiOnsidGhlbWUiOiJkZWZhdWx0In0sInVwZGF0ZUVkaXRvciI6ZmFsc2V9)
|
||||
|
||||
<!-- original mermaid graph
|
||||
graph TD;
|
||||
gnd[Ground Station] --MAVLink-- > rad1[Ground Radio];
|
||||
rad1 --RadioProtocol-- > rad2[Vehicle Radio];
|
||||
rad2 --MAVLink-- > a[Autopilot];
|
||||
-->
|
||||
|
||||
### Бортовий процесор
|
||||
|
||||
Невеликий комп'ютер, підключений до транспортного засобу, підключений до автопілота через послідовний порт або Ehthernet.
|
||||
Тут багато можливостей і це буде залежати від того, яку додаткову обробку ви хочете виконати на платі, а також від додаткової відправки команд до автопілота.
|
||||
Some examples are provided in [Companion Computers](../companion_computer/index.md#companion-computer-options).
|
||||
|
||||
[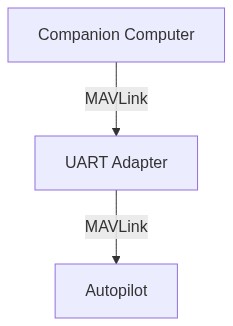](https://mermaid-js.github.io/mermaid-live-editor/#/edit/eyJjb2RlIjoiZ3JhcGggVEQ7XG4gIGNvbXBbQ29tcGFuaW9uIENvbXB1dGVyXSAtLU1BVkxpbmstLT4gdWFydFtVQVJUIEFkYXB0ZXJdO1xuICB1YXJ0IC0tTUFWTGluay0tPiBBdXRvcGlsb3Q7IiwibWVybWFpZCI6eyJ0aGVtZSI6ImRlZmF1bHQifSwidXBkYXRlRWRpdG9yIjpmYWxzZX0)
|
||||
|
||||
<!-- original mermaid graph
|
||||
graph TD;
|
||||
comp[Companion Computer] --MAVLink-- > uart[UART Adapter];
|
||||
uart --MAVLink-- > Autopilot;
|
||||
-->
|
||||
|
||||
### On-board processor and wifi link to ROS (**_Recommended_**)
|
||||
|
||||
Невеликий комп'ютер, підключений до транспортного засобу, підключений до автопілота через UART до USB-адаптера в той час, як підключений WiFi до наземної станції з запущеним ROS.
|
||||
Це може бути будь-який з комп'ютерів зазначеної секції в поєднанні з Wi-Fi адаптером.
|
||||
|
||||
[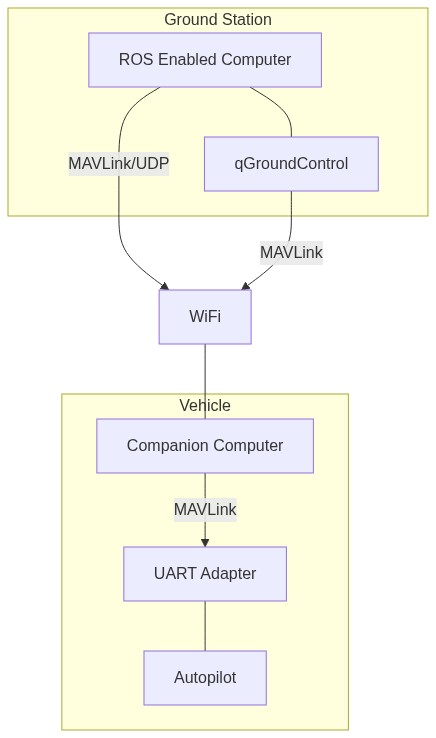](https://mermaid-js.github.io/mermaid-live-editor/#/edit/eyJjb2RlIjoiZ3JhcGggVERcbiAgc3ViZ3JhcGggR3JvdW5kICBTdGF0aW9uXG4gIGduZFtST1MgRW5hYmxlZCBDb21wdXRlcl0gLS0tIHFnY1txR3JvdW5kQ29udHJvbF1cbiAgZW5kXG4gIGduZCAtLU1BVkxpbmsvVURQLS0-IHdbV2lGaV07XG4gIHFnYyAtLU1BVkxpbmstLT4gdztcbiAgc3ViZ3JhcGggVmVoaWNsZVxuICBjb21wW0NvbXBhbmlvbiBDb21wdXRlcl0gLS1NQVZMaW5rLS0-IHVhcnRbVUFSVCBBZGFwdGVyXVxuICB1YXJ0IC0tLSBBdXRvcGlsb3RcbiAgZW5kXG4gIHcgLS0tIGNvbXAiLCJtZXJtYWlkIjp7InRoZW1lIjoiZGVmYXVsdCJ9LCJ1cGRhdGVFZGl0b3IiOmZhbHNlfQ)
|
||||
|
||||
<!-- original mermaid graph
|
||||
graph TD
|
||||
subgraph Ground Station
|
||||
gnd[ROS Enabled Computer] --- qgc[qGroundControl]
|
||||
end
|
||||
gnd --MAVLink/UDP-- > w[WiFi];
|
||||
qgc --MAVLink-- > w;
|
||||
subgraph Vehicle
|
||||
comp[Companion Computer] --MAVLink-- > uart[UART Adapter]
|
||||
uart --- Autopilot
|
||||
end
|
||||
w --- comp
|
||||
-->
|
||||
@@ -0,0 +1,43 @@
|
||||
# Raspberry Pi - встановлення ROS
|
||||
|
||||
Це посібник про те, як встановити ROS-indigo на Raspberry Pi 2 який виступає комп'ютером компаньйоном для Pixhawk.
|
||||
|
||||
## Вимоги
|
||||
|
||||
- Робочий Raspberry Pi з монітором, клавіатурою, або налаштованим SSH з'єднанням
|
||||
- Цей посібник передбачає, що у вас є Raspbian "JESSIE", встановлений на вашому RPi. If not: [install it](https://www.raspberrypi.org/downloads/raspbian/) or [upgrade](http://raspberrypi.stackexchange.com/questions/27858/upgrade-to-raspbian-jessie) your Raspbian Wheezy to Jessie.
|
||||
|
||||
## Встановлення
|
||||
|
||||
Follow [this guide](http://wiki.ros.org/ROSberryPi/Installing%20ROS%20Indigo%20on%20Raspberry%20Pi) for the actual installation of ROS Indigo. Примітка: встановіть варіант "ROS-Comm". Варіант Desktop занадто важкий.
|
||||
|
||||
### Помилки при встановленні пакетів
|
||||
|
||||
If you want to download packages (e.g. `sudo apt-get install ros-indigo-ros-tutorials`), you might get an error saying: "unable to locate package ros-indigo-ros-tutorials".
|
||||
|
||||
Якщо так, продовжуйте наступним чином:
|
||||
Перейдіть до свого catkin робочого простору (наприклад, ~/ros_catkin_ws) та змініть ім'я пакетів.
|
||||
|
||||
```sh
|
||||
$ cd ~/ros_catkin_ws
|
||||
|
||||
$ rosinstall_generator ros_tutorials --rosdistro indigo --deps --wet-only --exclude roslisp --tar > indigo-custom_ros.rosinstall
|
||||
```
|
||||
|
||||
Далі, оновіть своє робоче середовище з wstool.
|
||||
|
||||
```sh
|
||||
$ wstool merge -t src indigo-custom_ros.rosinstall
|
||||
|
||||
$ wstool update -t src
|
||||
```
|
||||
|
||||
Далі (досі у вашому робочому середовищі).
|
||||
|
||||
```sh
|
||||
$ source /opt/ros/indigo/setup.bash
|
||||
|
||||
$ source devel/setup.bash
|
||||
|
||||
$ catkin_make
|
||||
```
|
||||
@@ -0,0 +1,28 @@
|
||||
# ROS 1 (Deprecated)
|
||||
|
||||
:::warning
|
||||
The PX4 development team recommend that users migrate to [ROS 2](../ros2/index.md) (i.e. skip this section)!
|
||||
|
||||
ROS 1 is now "discommended" as the last LTS version is approaching end of life.
|
||||
ROS 2 has much deeper integration with PX4, enabling lower-latency communication with access to PX4 internal messaging.
|
||||
:::
|
||||
|
||||
[ROS (1)](http://www.ros.org/) is a general purpose robotics library that can be used with PX4 for drone application development.
|
||||
|
||||
This version of ROS uses the [MAVROS](../ros/mavros_installation.md) package to communicate with PX4 over [MAVLink](../middleware/mavlink.md) (MAVROS bridges ROS topics to MAVLink and PX4 conventions).
|
||||
|
||||
## Topics
|
||||
|
||||
- [ROS/MAVROS Installation Guide](../ros/mavros_installation.md): Setup a PX4 development environment with ROS 1 and MAVROS.
|
||||
- [ROS/MAVROS Offboard Example (C++)](../ros/mavros_offboard_cpp.md): Tutorial showing the main concepts related to writing a C++ MAVROS/ROS node.
|
||||
- [ROS MAVROS Sending Custom Messages](../ros/mavros_custom_messages.md)
|
||||
- [ROS with Gazebo Classic Simulation](../simulation/ros_interface.md)
|
||||
- [Gazebo Classic OctoMap Models with ROS](../sim_gazebo_classic/octomap.md)
|
||||
- [ROS Installation on RPi](../ros/raspberrypi_installation.md)
|
||||
- [External Position Estimation (Vision/Motion based)](../ros/external_position_estimation.md)
|
||||
|
||||
## Further Infomration
|
||||
|
||||
- [XTDrone](https://github.com/robin-shaun/XTDrone/blob/master/README.en.md) - ROS + PX4 simulation environment for computer vision.
|
||||
The [XTDrone Manual](https://www.yuque.com/xtdrone/manual_en) has everything you need to get started!
|
||||
- [Prometheus Autonomous Drone Project](https://github.com/amov-lab/Prometheus/blob/master/README_EN.md) - Prometheus is a ROS 1 based, BSD-3 licensed collection of autonomous drone software packages from [AMOVLab](https://github.com/amov-lab), which provides a full set of solutions for the intelligent and autonomous flight of drones, such as mapping, localization, planning, control, and target detection, fully integrated with the [Gazebo Classic](../sim_gazebo_classic/index.md) Simulator.
|
||||
@@ -0,0 +1 @@
|
||||
<Redirect to="../ros2/" />
|
||||
@@ -0,0 +1 @@
|
||||
<Redirect to="../ros2/user_guide" />
|
||||
@@ -0,0 +1 @@
|
||||
<Redirect to="../ros2/multi_vehicle" />
|
||||
@@ -0,0 +1 @@
|
||||
<Redirect to="../ros2/offboard_control" />
|
||||
Reference in New Issue
Block a user