mirror of
https://gitee.com/mirrors_PX4/PX4-Autopilot.git
synced 2026-10-24 17:03:33 +08:00
docs(i18n): PX4 guide translations (Crowdin) - uk (#26899)
Co-authored-by: Crowdin Bot <support+bot@crowdin.com>
This commit is contained in:
 PX4 Build Bot
co-authored by
Crowdin Bot
Crowdin Bot
parent
106907bfd4
commit
757be36ac2
@@ -22,37 +22,31 @@ jMAVSim can also be used for HITL Simulation ([as shown here](../simulation/hitl
|
||||
|
||||
## Встановлення
|
||||
|
||||
jMAVSim setup is included in our [standard build instructions](../dev_setup/dev_env.md) for Ubuntu Linux and Windows.
|
||||
Follow the instructions below to install jMAVSim on macOS.
|
||||
jMAVSim requires JDK 17 or later.
|
||||
On Ubuntu and Windows, the [standard development environment setup](../dev_setup/dev_env.md) scripts install all required dependencies including Java.
|
||||
On macOS, you need to install Java manually as shown below.
|
||||
|
||||
### macOS
|
||||
|
||||
To setup the environment for [jMAVSim](../sim_jmavsim/index.md) simulation:
|
||||
jMAVSim requires OpenJDK 17 or later.
|
||||
Install it via Homebrew:
|
||||
|
||||
1. Install a recent version of Java (e.g. Java 15).
|
||||
You can download [Java 15 (or later) from Oracle](https://www.oracle.com/java/technologies/downloads/?er=221886) or use [Eclipse Temurin](https://adoptium.net):
|
||||
```sh
|
||||
brew install openjdk@17
|
||||
```
|
||||
|
||||
```sh
|
||||
brew install --cask temurin
|
||||
```
|
||||
Homebrew installs OpenJDK but does not link it into your `PATH`, so you need to set `JAVA_HOME` for jMAVSim to find it.
|
||||
Add this to your shell profile (e.g. `~/.zshrc`):
|
||||
|
||||
2. Install jMAVSim:
|
||||
|
||||
```sh
|
||||
brew install px4-sim-jmavsim
|
||||
```
|
||||
|
||||
:::warning
|
||||
PX4 v1.11 and beyond require at least JDK 15 for jMAVSim simulation.
|
||||
|
||||
For earlier versions, macOS users might see the error `Exception in thread "main" java.lang.UnsupportedClassVersionError:`.
|
||||
You can find the fix in the [jMAVSim with SITL > Troubleshooting](../sim_jmavsim/index.md#troubleshooting)).
|
||||
|
||||
:::
|
||||
```sh
|
||||
export JAVA_HOME=$(/usr/libexec/java_home -v 17)
|
||||
```
|
||||
|
||||
## Середовище симуляції
|
||||
|
||||
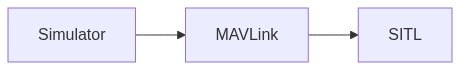
Симуляція програмного забезпечення в петлі виконує повну систему на комп'ютері та моделює автопілот. Він підключається через локальну мережу до симулятора. Вигляд налаштування виглядає наступним чином:
|
||||
Симуляція програмного забезпечення в петлі виконує повну систему на комп'ютері та моделює автопілот.
|
||||
Він підключається через локальну мережу до симулятора.
|
||||
Вигляд налаштування виглядає наступним чином:
|
||||
|
||||
[](https://mermaid-js.github.io/mermaid-live-editor/#/edit/eyJjb2RlIjoiZ3JhcGggTFI7XG4gIFNpbXVsYXRvci0tPk1BVkxpbms7XG4gIE1BVkxpbmstLT5TSVRMOyIsIm1lcm1haWQiOnsidGhlbWUiOiJkZWZhdWx0In0sInVwZGF0ZUVkaXRvciI6ZmFsc2V9)
|
||||
|
||||
@@ -95,7 +89,8 @@ It will also bring up a window showing a 3D view of the [jMAVSim](https://github
|
||||
|
||||
## Підйом у небо
|
||||
|
||||
Система почне друкувати інформацію про статус. You will be able to start flying once you have a position lock (shortly after the console displays the message: _EKF commencing GPS fusion_).
|
||||
Система почне друкувати інформацію про статус.
|
||||
You will be able to start flying once you have a position lock (shortly after the console displays the message: _EKF commencing GPS fusion_).
|
||||
|
||||
Щоб злітіти, введіть наступне у консоль:
|
||||
|
||||
@@ -220,11 +215,13 @@ To disable lockstep in:
|
||||
|
||||
## Розширення та персоналізація
|
||||
|
||||
To extend or customize the simulation interface, edit the files in the **Tools/jMAVSim** folder. The code can be accessed through the[jMAVSim repository](https://github.com/px4/jMAVSim) on Github.
|
||||
To extend or customize the simulation interface, edit the files in the **Tools/jMAVSim** folder.
|
||||
The code can be accessed through the[jMAVSim repository](https://github.com/px4/jMAVSim) on Github.
|
||||
|
||||
:::info
|
||||
The build system enforces the correct submodule to be checked out for all dependencies, including the simulator.
|
||||
Це не перезапише зміни в файлах у каталозі, проте, коли ці зміни будуть зафіксовані, підмодуль повинен бути зареєстрований у репозиторії Firmware з новим хешем коміту. To do so, `git add Tools/jMAVSim` and commit the change.
|
||||
Це не перезапише зміни в файлах у каталозі, проте, коли ці зміни будуть зафіксовані, підмодуль повинен бути зареєстрований у репозиторії Firmware з новим хешем коміту.
|
||||
To do so, `git add Tools/jMAVSim` and commit the change.
|
||||
Це оновить хеш GIT симулятора.
|
||||
:::
|
||||
|
||||
@@ -237,6 +234,75 @@ The simulation can be [interfaced to ROS](../simulation/ros_interface.md) the sa
|
||||
- The startup scripts are discussed in [System Startup](../concept/system_startup.md).
|
||||
- The simulated root file system ("`/`" directory) is created inside the build directory here: `build/px4_sitl_default/rootfs`.
|
||||
|
||||
## Display-Only Mode
|
||||
|
||||
jMAVSim can run as a display-only renderer for other simulators (like [SIH](../sim_sih/index.md)), with its internal physics disabled.
|
||||
In this mode, jMAVSim receives vehicle position via MAVLink and only renders the 3D view.
|
||||
|
||||
To use jMAVSim as a display for SIH running in SITL:
|
||||
|
||||
```sh
|
||||
# Start SIH first
|
||||
make px4_sitl_sih sihsim_quadx
|
||||
|
||||
# In another terminal, start jMAVSim in display-only mode
|
||||
./Tools/simulation/jmavsim/jmavsim_run.sh -p 19410 -u -q -o # 19410 is the default SIH display port
|
||||
```
|
||||
|
||||
For SIH running on flight controller hardware:
|
||||
|
||||
```sh
|
||||
./Tools/simulation/jmavsim/jmavsim_run.sh -q -d /dev/ttyACM0 -b 2000000 -o
|
||||
```
|
||||
|
||||
Use `-a` for airplane display or `-t` for tailsitter display.
|
||||
|
||||
## Command-Line Reference
|
||||
|
||||
The `jmavsim_run.sh` launch script accepts the following flags:
|
||||
|
||||
| Flag | Опис |
|
||||
| ------------- | -------------------------------------------------------------------------------------------- |
|
||||
| `-b <rate>` | Serial baud rate (default: 921600) |
|
||||
| `-d <device>` | Serial device path (e.g., `/dev/ttyACM0`) |
|
||||
| `-u` | Use UDP connection instead of serial |
|
||||
| `-i <id>` | Simulated MAVLink system ID |
|
||||
| `-p <port>` | UDP port (default: 14560) |
|
||||
| `-q` | No interactive console |
|
||||
| `-s <port>` | TCP serial port |
|
||||
| `-r <rate>` | Render rate in Hz |
|
||||
| `-l` | Enable lockstep |
|
||||
| `-o` | Display-only mode (disable physics, render only) |
|
||||
| `-a` | Use airplane model |
|
||||
| `-t` | Use tailsitter model |
|
||||
| `HEADLESS=1` | Environment variable: run without GUI window |
|
||||
|
||||
## How jMAVSim Works
|
||||
|
||||
jMAVSim is a Java-based lightweight simulator that communicates with PX4 via MAVLink HIL (Hardware-In-the-Loop) messages.
|
||||
|
||||
In normal mode:
|
||||
|
||||
1. PX4 sends actuator commands via [HIL_ACTUATOR_CONTROLS](https://mavlink.io/en/messages/common.html#HIL_ACTUATOR_CONTROLS).
|
||||
2. jMAVSim runs its physics engine to compute the vehicle state.
|
||||
3. jMAVSim sends sensor data back via [HIL_SENSOR](https://mavlink.io/en/messages/common.html#HIL_SENSOR) and [HIL_GPS](https://mavlink.io/en/messages/common.html#HIL_GPS).
|
||||
|
||||
In **display-only mode** (`-o` flag), jMAVSim disables its physics engine and only reads [HIL_STATE_QUATERNION](https://mavlink.io/en/messages/common.html#HIL_STATE_QUATERNION) messages to render the vehicle position.
|
||||
This allows it to visualize vehicles from other simulators like SIH.
|
||||
|
||||
jMAVSim supports [lockstep synchronization](#lockstep) with PX4 (enabled with `-l` flag), ensuring deterministic simulation results.
|
||||
|
||||
## Keyboard Shortcuts
|
||||
|
||||
Camera modes in the jMAVSim 3D view:
|
||||
|
||||
| Key | Camera Mode |
|
||||
| -------------------------------- | ------------------------------------------------------- |
|
||||
| **F** | First person (attached to vehicle) |
|
||||
| **S** | Stationary (fixed position) |
|
||||
| **G** | Gimbal (follows vehicle orientation) |
|
||||
| **(default)** | Third person follow |
|
||||
|
||||
## Усунення проблем
|
||||
|
||||
### java.long.NoClassDefFoundError
|
||||
@@ -327,8 +393,8 @@ Exception in thread "main" java.lang.UnsupportedClassVersionError: me/drton/jmav
|
||||
Ця помилка говорить вам, вам потрібна більш свіжа версія Java у вашому середовищі.
|
||||
Версія файлу класу 58 відповідає jdk14, версія 59 - jdk15, версія 60 - jdk 16 тощо.
|
||||
|
||||
Щоб виправити це під macOS, ми рекомендуємо встановити OpenJDK через homebrew
|
||||
To fix it under macOS, install a newer OpenJDK via Homebrew:
|
||||
|
||||
```sh
|
||||
brew install --cask adoptopenjdk16
|
||||
brew install openjdk@17
|
||||
```
|
||||
|
||||
Reference in New Issue
Block a user